Radio telescope
Tracking dish with a supporting truss
Earlier examples from earlier Kiln versions.
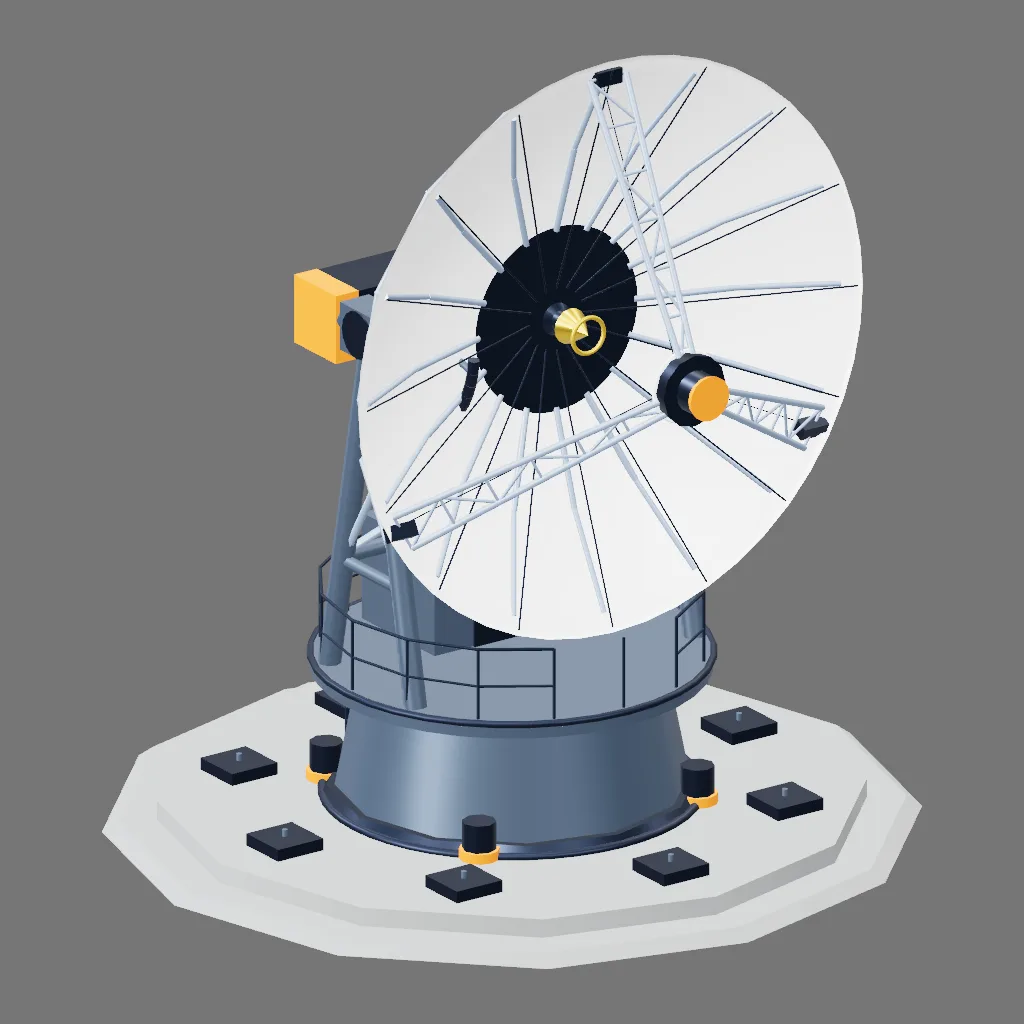
Drag to orbit after opening. The model starts stationary.
For your engine. The download is a standard glTF 2.0 binary (GLB) with PBR metallic-roughness materials. glTF stores materials, not lighting or tone mapping, so your engine decides how they read. This 3D view tone-maps with Review Neutral, the Khronos PBR Neutral construction with a smaller glare offset (0.015 instead of 0.04), at exposure 0.9. Its Tone mapping control also shows ACES and Linear, for comparison.
Build measurements
- Triangles
- 16,532
- Estimated draws
- 416
- Materials
- 7
- Textures
- 0
- Animation clips
- 1
- Bounds X × Y × Z
- 10.4 × 10.96 × 10.4 m
- Build warnings
- 0
Measurements come from this build.
Download this build
Runtime: 332,520 bytes. Original: 332,288 bytes.
These GLBs are build outputs of the MIT-licensed example source; no separate terms are stated for the builds.
Runtime provenance metadataSHA-256 download hashes
- Runtime GLB
- 8dabfc3e8b6b3ffa74228ffebbf774a7394fa119cad09c942acd2904651252e2
- Original GLB
- 174ea32c288cf88d9297ca07be02ac1fb3c50716a951af09ae5cf044653b0911
- Source
- 6414ad919135ddcd1443d1add8973dcfc99ffd95f66590219491fbe9d8951605
The example source is part of the Kiln repository. Repository licence: MIT.
These GLBs are build outputs of the MIT-licensed example source; no separate terms are stated for the builds.
Recorded authorship
Gemini 3.8 Flash through Antigravity CLI (agy)
Source-header credit
- Source access
- Not recorded
- Inherited context
- Not independently recorded; source-header declarations only
- Starting example
- Not recorded
- Human input
- Header declares no hand-authored source; other intervention not recorded
- Authoring review
- Six-view review declared; renderer fidelity not recorded
Gallery GPU render of this exact source. Source, artifact, image hashes and camera settings are recorded alongside the poster; the artifact hash names the GLB bytes the image was rendered from, which the downloadable rebuild reproduces byte for byte only on the platform that recorded it.
Poster camera and render recordThe source behind this build
// Authored by: gemini-3.8-flash-high, via agy.
//
// Written by the model itself through the Kiln MCP tools: it wrote the
// program, rendered it, looked at its own six-view contact sheet, and
// revised. Not a line of it is hand-authored.

const meta = { name: 'RadioTelescope', category: 'prop' };

function build() {
  const root = createRoot('RadioTelescope');

  // Materials
  const concreteMat = gameMaterial(0x828585, { roughness: 0.95, metalness: 0.05 });
  const dishWhiteMat = gameMaterial(0xededec, { roughness: 0.55, metalness: 0.15 });
  const dishRearMat = gameMaterial(0xc5cad1, { roughness: 0.65, metalness: 0.25 });
  const steelMountMat = gameMaterial(0x526173, { roughness: 0.45, metalness: 0.65 });
  const steelTrussMat = gameMaterial(0x8da0b8, { roughness: 0.4, metalness: 0.55 });
  const machineryDarkMat = gameMaterial(0x273142, { roughness: 0.35, metalness: 0.8 });
  const accentYellowMat = gameMaterial(0xd97706, { roughness: 0.4, metalness: 0.15 });
  const goldMat = gameMaterial(0xd4af37, { roughness: 0.25, metalness: 0.9 });

  // ---------------------------------------------------------------------------
  // 1. STATIONARY PEDESTAL & FOUNDATION (Y = 0 to Y = 2.20m)
  // ---------------------------------------------------------------------------

  // Concrete foundation pad (sitting directly on Y = 0)
  createPart('PadBase', cylinderGeo(5.0, 5.2, 0.15, 12), concreteMat, {
    position: [0, 0.075, 0],
    parent: root,
  });
  createPart('PadOctagon', cylinderGeo(4.5, 4.5, 0.25, 12), concreteMat, {
    position: [0, 0.275, 0],
    parent: root,
  });

  // 8 radial foundation anchor piers with bolt fixtures
  for (let i = 0; i < 8; i++) {
    const angle = (i / 8) * Math.PI * 2;
    const fx = Math.cos(angle) * 3.5;
    const fz = Math.sin(angle) * 3.5;
    createPart(`AnchorFoot_${i}`, boxGeo(0.7, 0.22, 0.7), machineryDarkMat, {
      position: [fx, 0.45, fz],
      parent: root,
    });
    createPart(`AnchorBolt_${i}`, cylinderGeo(0.04, 0.04, 0.1, 6), steelMountMat, {
      position: [fx, 0.6, fz],
      parent: root,
    });
  }

  // Circular azimuth rail track ring
  const azRailGeo = torusGeo(2.4, 0.06, 12, 48);
  createPart('AzimuthTrack', azRailGeo, machineryDarkMat, {
    position: [0, 0.42, 0],
    rotation: [90, 0, 0],
    parent: root,
  });

  // Stationary pedestal column (tapered 12-sided structural tower)
  createPart('PedestalBaseFlange', cylinderGeo(2.35, 2.45, 0.15, 12), machineryDarkMat, {
    position: [0, 0.475, 0],
    parent: root,
  });
  createPart('PedestalColumn', cylinderGeo(1.95, 2.25, 1.55, 12), steelMountMat, {
    position: [0, 1.325, 0],
    parent: root,
  });
  createPart('PedestalTopFlange', cylinderGeo(2.15, 1.95, 0.15, 12), machineryDarkMat, {
    position: [0, 2.15, 0],
    parent: root,
  });

  // Pedestal maintenance access door on -X side
  createPart('PedestalDoorFrame', boxGeo(0.08, 1.25, 0.75), machineryDarkMat, {
    position: [-2.05, 1.2, 0],
    parent: root,
  });
  createPart('PedestalDoor', boxGeo(0.04, 1.15, 0.65), accentYellowMat, {
    position: [-2.07, 1.2, 0],
    parent: root,
  });

  // 4 stationary azimuth drive units
  for (let i = 0; i < 4; i++) {
    const ang = (i / 4) * Math.PI * 2 + Math.PI / 4;
    const mx = Math.cos(ang) * 2.38;
    const mz = Math.sin(ang) * 2.38;
    createPart(`AzDriveMotor_${i}`, cylinderGeo(0.22, 0.22, 0.5, 8), machineryDarkMat, {
      position: [mx, 0.65, mz],
      parent: root,
    });
    createPart(`AzDriveGear_${i}`, cylinderGeo(0.26, 0.26, 0.16, 12), accentYellowMat, {
      position: [mx, 0.45, mz],
      parent: root,
    });
  }

  // Rotary cable festoon guide on pedestal below turntable
  const cableGuide = torusGeo(2.1, 0.04, 8, 24);
  createPart('AzCableGuide', cableGuide, machineryDarkMat, {
    position: [0, 2.05, 0],
    rotation: [90, 0, 0],
    parent: root,
  });

  // Exterior ground-to-turntable access ladder
  createLadder('GroundLadder', {
    bottom: [-2.42, 0.4, 0.7],
    top: [-2.42, 2.2, 0.7],
    width: 0.45,
    rungCount: 6,
    material: machineryDarkMat,
    parent: root,
  });

  // ---------------------------------------------------------------------------
  // 2. AZIMUTH MOUNT & YOKE (Joint_Azimuth, Y = 2.20m)
  // ---------------------------------------------------------------------------
  const azPivotPos = [0, 2.20, 0];
  const azDeckGeo = cylinderGeo(2.55, 2.55, 0.22, 36);
  const jointAzimuth = createPart('Azimuth', azDeckGeo, steelMountMat, {
    position: azPivotPos,
    pivot: azPivotPos,
    parent: root,
  });
  jointAzimuth.name = 'Joint_Azimuth';

  // Turntable deck perimeter trim
  createPart('DeckRim', torusGeo(2.55, 0.05, 8, 36), machineryDarkMat, {
    position: [0, 0.08, 0],
    rotation: [90, 0, 0],
    parent: jointAzimuth,
  });

  // Perimeter handrail (open in front sector for dish swing clearance)
  const railRadius = 2.46;
  const numRailPosts = 16;
  for (let i = 0; i < numRailPosts; i++) {
    const a1 = (i / numRailPosts) * Math.PI * 2;
    const a2 = ((i + 1) / numRailPosts) * Math.PI * 2;
    const midAngle = (a1 + a2) / 2;
    const isFrontSector = Math.abs(midAngle) < 0.4 || Math.abs(midAngle - Math.PI * 2) < 0.4;

    const px = Math.cos(a1) * railRadius;
    const pz = Math.sin(a1) * railRadius;
    const nx = Math.cos(a2) * railRadius;
    const nz = Math.sin(a2) * railRadius;

    createPart(`RailPost_${i}`, cylinderGeo(0.022, 0.022, 0.95, 6), machineryDarkMat, {
      position: [px, 0.58, pz],
      parent: jointAzimuth,
    });

    if (!isFrontSector) {
      beamBetween(`RailTop_${i}`, [px, 1.05, pz], [nx, 1.05, nz], 0.022, machineryDarkMat, {
        segments: 6,
        parent: jointAzimuth,
      });
      beamBetween(`RailMid_${i}`, [px, 0.55, pz], [nx, 0.55, nz], 0.018, machineryDarkMat, {
        segments: 6,
        parent: jointAzimuth,
      });
    }
  }

  // Equipment / Machinery cabin on turntable deck (-X)
  createPart('EquipCabin', boxGeo(1.6, 1.45, 1.9), steelMountMat, {
    position: [-1.15, 0.82, 0],
    parent: jointAzimuth,
  });
  createPart('CabinDoor', boxGeo(0.04, 1.25, 0.7), machineryDarkMat, {
    position: [-0.33, 0.72, 0],
    parent: jointAzimuth,
  });
  createPart('CabinHvac', boxGeo(0.7, 0.4, 0.9), machineryDarkMat, {
    position: [-1.15, 1.75, 0],
    parent: jointAzimuth,
  });
  createPart('CabinHvacFan', cylinderYGeo(0.25, 0.25, 0.06, 12), accentYellowMat, {
    position: [-1.15, 1.98, 0],
    parent: jointAzimuth,
  });

  // Twin A-frame Stanchion Towers
  const towerZ = 2.15;
  const towerHeight = 4.90; // World Y = 7.10m for complete dish clearance
  [-towerZ, towerZ].forEach((tz, idx) => {
    const side = idx === 0 ? 'L' : 'R';

    // Front main column
    beamBetween(`TowerFront_${side}`, [0.95, 0.1, tz], [0, towerHeight, tz], 0.15, steelMountMat, {
      segments: 8,
      parent: jointAzimuth,
    });
    // Rear main column
    beamBetween(`TowerRear_${side}`, [-0.95, 0.1, tz], [0, towerHeight, tz], 0.15, steelMountMat, {
      segments: 8,
      parent: jointAzimuth,
    });
    // Horizontal cross ties
    beamBetween(`TowerCrossLow_${side}`, [0.65, 1.6, tz], [-0.65, 1.6, tz], 0.08, steelMountMat, {
      segments: 6,
      parent: jointAzimuth,
    });
    beamBetween(`TowerCrossHigh_${side}`, [0.35, 3.3, tz], [-0.35, 3.3, tz], 0.08, steelMountMat, {
      segments: 6,
      parent: jointAzimuth,
    });
    // Lattice X-braces
    beamBetween(`TowerDiagA_${side}`, [0.65, 1.6, tz], [-0.35, 3.3, tz], 0.05, steelTrussMat, {
      segments: 6,
      parent: jointAzimuth,
    });
    beamBetween(`TowerDiagB_${side}`, [-0.65, 1.6, tz], [0.35, 3.3, tz], 0.05, steelTrussMat, {
      segments: 6,
      parent: jointAzimuth,
    });

    // Top bearing block
    createPart(`BearingBlock_${side}`, boxGeo(0.8, 0.65, 0.45), steelMountMat, {
      position: [0, towerHeight, tz],
      parent: jointAzimuth,
    });
    createPart(`BearingCap_${side}`, cylinderZGeo(0.32, 0.32, 0.5, 16), machineryDarkMat, {
      position: [0, towerHeight, tz],
      parent: jointAzimuth,
    });
  });

  // Cross tie beams connecting Left and Right towers across back (-X)
  beamBetween('TowerTieLow', [-0.75, 1.6, -towerZ], [-0.75, 1.6, towerZ], 0.11, steelMountMat, {
    segments: 8,
    parent: jointAzimuth,
  });
  beamBetween('TowerTieHigh', [-0.4, 3.3, -towerZ], [-0.4, 3.3, towerZ], 0.11, steelMountMat, {
    segments: 8,
    parent: jointAzimuth,
  });
  beamBetween('TowerTieDiagA', [-0.75, 1.6, -towerZ], [-0.4, 3.3, towerZ], 0.06, steelTrussMat, {
    segments: 6,
    parent: jointAzimuth,
  });
  beamBetween('TowerTieDiagB', [-0.75, 1.6, towerZ], [-0.4, 3.3, -towerZ], 0.06, steelTrussMat, {
    segments: 6,
    parent: jointAzimuth,
  });

  // Tower ladder on Left tower up to elevation bearing platform
  createLadder('TowerLadderL', {
    bottom: [-0.95, 0.2, -towerZ - 0.22],
    top: [0, towerHeight - 0.4, -towerZ - 0.22],
    width: 0.4,
    rungCount: 14,
    material: machineryDarkMat,
    parent: jointAzimuth,
  });
  // Bearing maintenance platform on Left tower
  createPart('TowerPlatformL', boxGeo(0.8, 0.06, 0.8), machineryDarkMat, {
    position: [0, towerHeight - 0.35, -towerZ - 0.4],
    parent: jointAzimuth,
  });

  // Elevation drive motor and gearbox mounted on Right tower
  createPart('ElevDriveBox', boxGeo(0.55, 0.65, 0.45), machineryDarkMat, {
    position: [0.35, towerHeight - 0.55, towerZ - 0.3],
    parent: jointAzimuth,
  });
  createPart('ElevPinion', cylinderZGeo(0.18, 0.18, 0.3, 12), accentYellowMat, {
    position: [0.35, towerHeight - 0.55, towerZ - 0.62],
    parent: jointAzimuth,
  });

  // ---------------------------------------------------------------------------
  // 3. ELEVATION ASSEMBLY (Joint_Elevation, pivot at [0, towerHeight, 0])
  // ---------------------------------------------------------------------------
  const elPivotPos = [0, towerHeight, 0];
  const elAxleGeo = cylinderZGeo(0.24, 0.24, 4.3, 16);
  const jointElevation = createPart('Elevation', elAxleGeo, machineryDarkMat, {
    position: elPivotPos,
    pivot: elPivotPos,
    parent: jointAzimuth,
  });
  jointElevation.name = 'Joint_Elevation';

  // Semicircular Elevation Bull Gear Sector
  const gearZ = towerZ - 0.62;
  const gearR = 1.35;
  const gearSegments = 16;
  for (let g = 0; g < gearSegments; g++) {
    const a1 = -0.6 + (g / gearSegments) * 2.1;
    const a2 = -0.6 + ((g + 1) / gearSegments) * 2.1;
    const gx1 = Math.sin(a1) * gearR;
    const gy1 = -Math.cos(a1) * gearR;
    const gx2 = Math.sin(a2) * gearR;
    const gy2 = -Math.cos(a2) * gearR;

    beamBetween(`GearRim_${g}`, [gx1, gy1, gearZ], [gx2, gy2, gearZ], 0.08, machineryDarkMat, {
      segments: 6,
      parent: jointElevation,
    });
    if (g % 3 === 0) {
      beamBetween(`GearSpoke_${g}`, [0, 0, gearZ], [gx1, gy1, gearZ], 0.05, steelMountMat, {
        segments: 6,
        parent: jointElevation,
      });
    }
    createPart(`GearTooth_${g}`, boxGeo(0.08, 0.05, 0.12), accentYellowMat, {
      position: [gx1, gy1, gearZ],
      rotation: [0, 0, (a1 * 180) / Math.PI],
      parent: jointElevation,
    });
  }

  // Heavy Boxed Counterweight System
  const cwZ = 1.55;
  [-cwZ, cwZ].forEach((cz, idx) => {
    const side = idx === 0 ? 'L' : 'R';
    beamBetween(`CwArm_${side}`, [0, 0, cz], [-1.8, -0.5, cz], 0.22, steelMountMat, {
      segments: 6,
      parent: jointElevation,
    });
    beamBetween(`CwBrace_${side}`, [0.5, 0, cz * 0.7], [-1.8, -0.5, cz], 0.09, steelTrussMat, {
      segments: 6,
      parent: jointElevation,
    });
  });

  // Main transverse counterweight ballast block
  createPart('CwBallastMain', boxGeo(0.9, 0.9, 3.4), machineryDarkMat, {
    position: [-1.8, -0.5, 0],
    parent: jointElevation,
  });
  createPart('CwBallastEndL', boxGeo(0.92, 0.92, 0.35), accentYellowMat, {
    position: [-1.8, -0.5, -1.6],
    parent: jointElevation,
  });
  createPart('CwBallastEndR', boxGeo(0.92, 0.92, 0.35), accentYellowMat, {
    position: [-1.8, -0.5, 1.6],
    parent: jointElevation,
  });

  // Central Torque Box / Dish Hub Cradle
  createPart('DishHubDrum', cylinderXGeo(1.25, 1.35, 0.85, 16), steelMountMat, {
    position: [0.5, 0, 0],
    parent: jointElevation,
  });
  createPart('DishHubFrontPlate', cylinderXGeo(1.4, 1.4, 0.12, 16), machineryDarkMat, {
    position: [0.92, 0, 0],
    parent: jointElevation,
  });

  // Structural cradle gussets between torque axle and hub
  [-1.2, 1.2].forEach((gz, gIdx) => {
    createPart(`HubGusset_${gIdx}`, boxGeo(0.6, 0.3, 0.08), steelMountMat, {
      position: [0.35, 0.2, gz],
      rotation: [0, 0, -25],
      parent: jointElevation,
    });
  });

  // ---------------------------------------------------------------------------
  // 4. PARABOLIC DISH REFLECTOR (Facing +X forward)
  // ---------------------------------------------------------------------------
  const dishVertexX = 0.92;
  const f4 = 11.2;
  const dishRadius = 3.8;
  const numRadSteps = 16;
  const dishProfile = [];

  for (let i = 0; i <= numRadSteps; i++) {
    const r = 0.25 + (dishRadius - 0.25) * (i / numRadSteps);
    const x = dishVertexX + (r * r) / f4;
    dishProfile.push([r, x]);
  }
  const rimX = dishVertexX + (dishRadius * dishRadius) / f4;
  dishProfile.push([dishRadius + 0.06, rimX]);
  dishProfile.push([dishRadius + 0.06, rimX - 0.08]);

  for (let i = numRadSteps; i >= 0; i--) {
    const r = 0.45 + (dishRadius - 0.45) * (i / numRadSteps);
    const x = dishVertexX + (r * r) / f4 - 0.08;
    dishProfile.push([r, x]);
  }
  dishProfile.push([0.45, dishVertexX - 0.06]);

  const dishGeo = revolveGeo(dishProfile, { axis: [1, 0, 0], segments: 48 });
  createPart('ParabolicDish', dishGeo, dishWhiteMat, {
    parent: jointElevation,
  });

  createPart('VertexCone', coneXGeo(0.28, 0.28, 16), machineryDarkMat, {
    position: [dishVertexX + 0.14, 0, 0],
    parent: jointElevation,
  });

  // 16 radial panel seams on front face
  const numSeams = 16;
  for (let i = 0; i < numSeams; i++) {
    const ang = (i / numSeams) * Math.PI * 2;
    const cosA = Math.cos(ang);
    const sinA = Math.sin(ang);
    const p1 = [dishVertexX + 0.02, cosA * 0.32, sinA * 0.32];
    const p2 = [rimX + 0.01, cosA * (dishRadius - 0.02), sinA * (dishRadius - 0.02)];
    beamBetween(`DishSeam_${i}`, p1, p2, 0.012, machineryDarkMat, {
      segments: 5,
      parent: jointElevation,
    });
  }

  // ---------------------------------------------------------------------------
  // 5. BACK-UP STRUCTURE (BUS) SPACE FRAME TRUSS
  // ---------------------------------------------------------------------------
  const busHubR = 1.2;
  const busHubX = 0.45;
  const busMidR = 2.45;
  const busMidX = dishVertexX + (busMidR * busMidR) / f4 - 0.45;
  const busRimR = 3.65;
  const busRimX = dishVertexX + (busRimR * busRimR) / f4 - 0.25;

  for (let i = 0; i < numSeams; i++) {
    const ang = (i / numSeams) * Math.PI * 2;
    const cosA = Math.cos(ang);
    const sinA = Math.sin(ang);

    const nHub = [busHubX, cosA * busHubR, sinA * busHubR];
    const nMidFront = [dishVertexX + (busMidR * busMidR) / f4 - 0.08, cosA * busMidR, sinA * busMidR];
    const nRimFront = [dishVertexX + (busRimR * busRimR) / f4 - 0.08, cosA * busRimR, sinA * busRimR];
    const nMidRear = [busMidX, cosA * busMidR, sinA * busMidR];
    const nRimRear = [busRimX, cosA * busRimR, sinA * busRimR];

    beamBetween(`BusRearChordInner_${i}`, nHub, nMidRear, 0.055, steelTrussMat, {
      segments: 6,
      parent: jointElevation,
    });
    beamBetween(`BusRearChordOuter_${i}`, nMidRear, nRimRear, 0.045, steelTrussMat, {
      segments: 6,
      parent: jointElevation,
    });

    beamBetween(`BusFrontChordInner_${i}`, [dishVertexX + 0.05, cosA * busHubR, sinA * busHubR], nMidFront, 0.045, steelTrussMat, {
      segments: 6,
      parent: jointElevation,
    });
    beamBetween(`BusFrontChordOuter_${i}`, nMidFront, nRimFront, 0.04, steelTrussMat, {
      segments: 6,
      parent: jointElevation,
    });

    beamBetween(`BusWebMid_${i}`, nMidFront, nMidRear, 0.04, steelTrussMat, {
      segments: 6,
      parent: jointElevation,
    });
    beamBetween(`BusWebRim_${i}`, nRimFront, nRimRear, 0.035, steelTrussMat, {
      segments: 6,
      parent: jointElevation,
    });
    beamBetween(`BusWebDiagInner_${i}`, [dishVertexX + 0.05, cosA * busHubR, sinA * busHubR], nMidRear, 0.035, steelTrussMat, {
      segments: 6,
      parent: jointElevation,
    });
    beamBetween(`BusWebDiagOuter_${i}`, nMidFront, nRimRear, 0.035, steelTrussMat, {
      segments: 6,
      parent: jointElevation,
    });

    const nextAng = ((i + 1) / numSeams) * Math.PI * 2;
    const nextCos = Math.cos(nextAng);
    const nextSin = Math.sin(nextAng);
    const nextMidRear = [busMidX, nextCos * busMidR, nextSin * busMidR];
    const nextRimRear = [busRimX, nextCos * busRimR, nextSin * busRimR];

    beamBetween(`BusRingMid_${i}`, nMidRear, nextMidRear, 0.045, steelTrussMat, {
      segments: 6,
      parent: jointElevation,
    });
    beamBetween(`BusRingRim_${i}`, nRimRear, nextRimRear, 0.04, steelTrussMat, {
      segments: 6,
      parent: jointElevation,
    });
  }

  // ---------------------------------------------------------------------------
  // 6. SYMMETRICAL LATTICE FEED TRIPOD & APEX RECEIVER
  // ---------------------------------------------------------------------------
  const focalX = dishVertexX + 2.80;
  const feedApexX = focalX + 0.28;

  // 3 tripod legs: Top (0°), Bottom-Right (120°), Bottom-Left (240°)
  const tripodPhis = [0, (2 * Math.PI) / 3, (4 * Math.PI) / 3];
  const legRimR = 3.65;
  const legRimX = dishVertexX + (legRimR * legRimR) / f4;
  const apexR = 0.32;
  const numLacingBays = 6;

  tripodPhis.forEach((phi, legIdx) => {
    const tag = ['Top', 'BotR', 'BotL'][legIdx];
    const ry = Math.cos(phi);
    const rz = Math.sin(phi);
    const ty = -Math.sin(phi);
    const tz = Math.cos(phi);

    const chordSpreadBase = 0.28;
    const chordSpreadApex = 0.10;

    const pOuterBase = [
      legRimX,
      ry * legRimR + ty * chordSpreadBase,
      rz * legRimR + tz * chordSpreadBase,
    ];
    const pInnerBase = [
      legRimX,
      ry * legRimR - ty * chordSpreadBase,
      rz * legRimR - tz * chordSpreadBase,
    ];
    const pOuterApex = [
      feedApexX - 0.12,
      ry * apexR + ty * chordSpreadApex,
      rz * apexR + tz * chordSpreadApex,
    ];
    const pInnerApex = [
      feedApexX - 0.12,
      ry * apexR - ty * chordSpreadApex,
      rz * apexR - tz * chordSpreadApex,
    ];

    beamBetween(`LegChordOuter_${tag}`, pOuterBase, pOuterApex, 0.045, steelTrussMat, {
      segments: 8,
      parent: jointElevation,
    });
    beamBetween(`LegChordInner_${tag}`, pInnerBase, pInnerApex, 0.045, steelTrussMat, {
      segments: 8,
      parent: jointElevation,
    });

    createPart(`LegFoot_${tag}`, boxGeo(0.2, 0.2, 0.38), machineryDarkMat, {
      position: [legRimX - 0.04, ry * legRimR, rz * legRimR],
      rotation: [0, 0, (phi * 180) / Math.PI],
      parent: jointElevation,
    });

    for (let b = 0; b < numLacingBays; b++) {
      const t0 = b / numLacingBays;
      const t1 = (b + 1) / numLacingBays;

      const o0 = [
        pOuterBase[0] + (pOuterApex[0] - pOuterBase[0]) * t0,
        pOuterBase[1] + (pOuterApex[1] - pOuterBase[1]) * t0,
        pOuterBase[2] + (pOuterApex[2] - pOuterBase[2]) * t0,
      ];
      const i0 = [
        pInnerBase[0] + (pInnerApex[0] - pInnerBase[0]) * t0,
        pInnerBase[1] + (pInnerApex[1] - pInnerBase[1]) * t0,
        pInnerBase[2] + (pInnerApex[2] - pInnerBase[2]) * t0,
      ];
      const o1 = [
        pOuterBase[0] + (pOuterApex[0] - pOuterBase[0]) * t1,
        pOuterBase[1] + (pOuterApex[1] - pOuterBase[1]) * t1,
        pOuterBase[2] + (pOuterApex[2] - pOuterBase[2]) * t1,
      ];
      const i1 = [
        pInnerBase[0] + (pInnerApex[0] - pInnerBase[0]) * t1,
        pInnerBase[1] + (pInnerApex[1] - pInnerBase[1]) * t1,
        pInnerBase[2] + (pInnerApex[2] - pInnerBase[2]) * t1,
      ];

      beamBetween(`LegSpacer_${tag}_${b}`, o0, i0, 0.022, steelTrussMat, {
        segments: 6,
        parent: jointElevation,
      });
      if (b % 2 === 0) {
        beamBetween(`LegDiag_${tag}_${b}`, o0, i1, 0.022, steelTrussMat, {
          segments: 6,
          parent: jointElevation,
        });
      } else {
        beamBetween(`LegDiag_${tag}_${b}`, i0, o1, 0.022, steelTrussMat, {
          segments: 6,
          parent: jointElevation,
        });
      }
    }

    // Subreflector apex mounting struts connecting hub to subreflector rim
    beamBetween(`SubrefStrut_${tag}`, [feedApexX - 0.1, ry * apexR, rz * apexR], [focalX + 0.05, ry * 0.45, rz * 0.45], 0.025, steelTrussMat, {
      segments: 6,
      parent: jointElevation,
    });
  });

  // Apex feed support collar
  createPart('ApexHubCollar', cylinderXGeo(0.48, 0.45, 0.25, 12), machineryDarkMat, {
    position: [feedApexX - 0.1, 0, 0],
    parent: jointElevation,
  });

  // Cassegrain Subreflector (hyperbolic dish facing backward -X)
  const subrefProfile = [
    [0.02, focalX - 0.04],
    [0.2, focalX - 0.03],
    [0.4, focalX],
    [0.48, focalX + 0.06],
    [0.5, focalX + 0.08],
    [0.48, focalX + 0.10],
    [0.2, focalX + 0.11],
    [0.02, focalX + 0.12],
  ];
  const subrefGeo = revolveGeo(subrefProfile, { axis: [1, 0, 0], segments: 32 });
  createPart('Subreflector', subrefGeo, dishWhiteMat, {
    parent: jointElevation,
  });

  // Cryogenic receiver dewar / electronics package behind subreflector
  createPart('ReceiverCanister', cylinderXGeo(0.28, 0.28, 0.45, 16), machineryDarkMat, {
    position: [focalX + 0.35, 0, 0],
    parent: jointElevation,
  });
  createPart('ReceiverEndCap', cylinderXGeo(0.3, 0.28, 0.08, 16), accentYellowMat, {
    position: [focalX + 0.60, 0, 0],
    parent: jointElevation,
  });

  // Gold primary feed horn at center of main dish
  createPart('FeedHornBase', cylinderXGeo(0.14, 0.14, 0.25, 16), machineryDarkMat, {
    position: [dishVertexX + 0.24, 0, 0],
    parent: jointElevation,
  });
  createPart('FeedHornCone', coneXGeo(0.24, 0.4, 16), goldMat, {
    position: [dishVertexX + 0.56, 0, 0],
    parent: jointElevation,
  });
  createPart('FeedHornFlare', torusGeo(0.24, 0.03, 8, 24), goldMat, {
    position: [dishVertexX + 0.76, 0, 0],
    rotation: [0, 90, 0],
    parent: jointElevation,
  });

  // 3 tension guy wires anchoring apex to dish rim
  tripodPhis.forEach((phi, idx) => {
    const ry = Math.cos(phi) * (dishRadius - 0.3);
    const rz = Math.sin(phi) * (dishRadius - 0.3);
    beamBetween(`GuyWire_${idx}`, [focalX, 0, 0], [legRimX - 0.1, ry, rz], 0.008, machineryDarkMat, {
      segments: 4,
      parent: jointElevation,
    });
  });

  return root;
}

function animate() {
  return [
    createClip('Scan', 8, [
      rotationTrack('Joint_Azimuth', [
        { time: 0, rotation: [0, 0, 0] },
        { time: 2, rotation: [0, 30, 0] },
        { time: 4, rotation: [0, 0, 0] },
        { time: 6, rotation: [0, -30, 0] },
        { time: 8, rotation: [0, 0, 0] },
      ]),
      rotationTrack('Joint_Elevation', [
        { time: 0, rotation: [0, 0, 10] },
        { time: 2, rotation: [0, 0, 35] },
        { time: 4, rotation: [0, 0, 60] },
        { time: 6, rotation: [0, 0, 35] },
        { time: 8, rotation: [0, 0, 10] },
      ]),
    ]),
  ];
}Scroll code horizontally
Brief and retained revisions
No brief or earlier revisions are recorded. The source download contains the version built for this page.