Harbour crane
Braced steel frame with suspended lifting gear
Earlier examples from earlier Kiln versions.
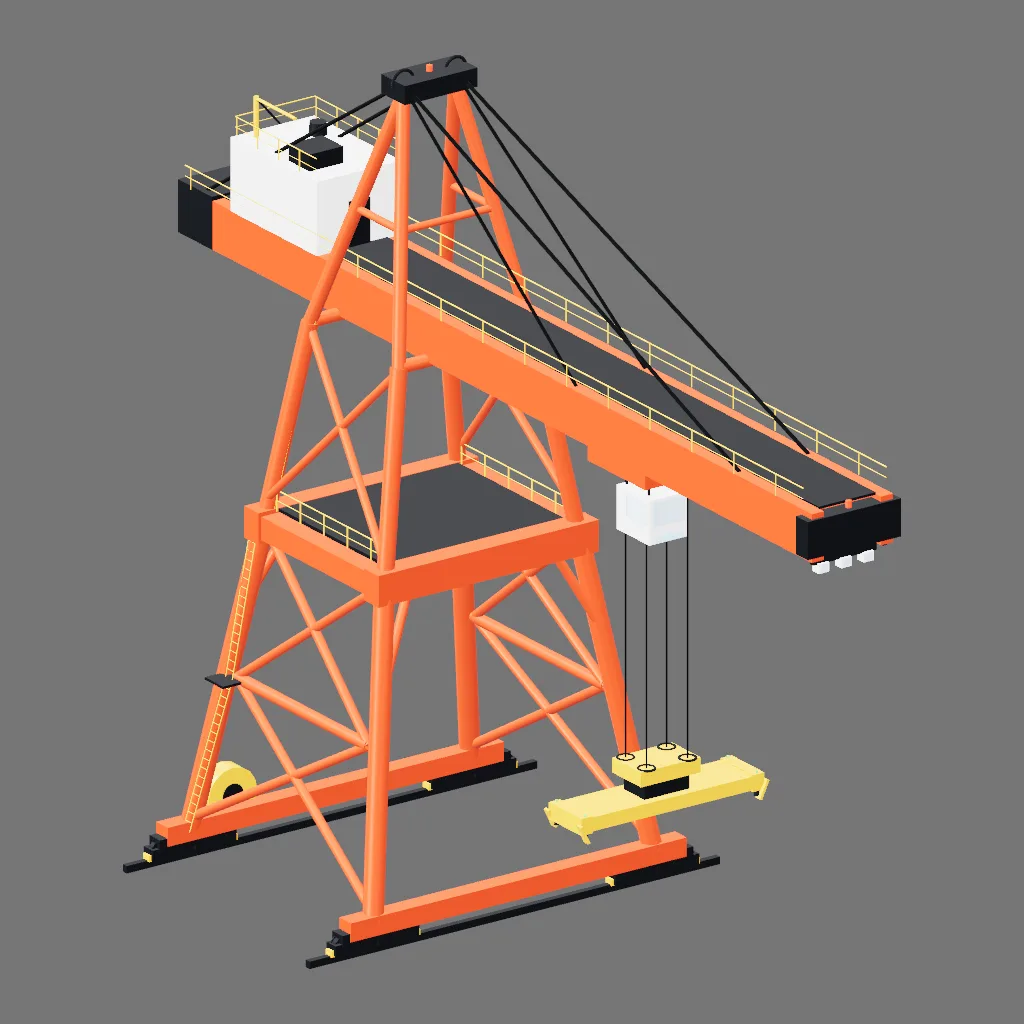
Drag to orbit after opening. The model starts stationary.
For your engine. The download is a standard glTF 2.0 binary (GLB) with PBR metallic-roughness materials. glTF stores materials, not lighting or tone mapping, so your engine decides how they read. This 3D view tone-maps with Review Neutral, the Khronos PBR Neutral construction with a smaller glare offset (0.015 instead of 0.04), at exposure 0.9. Its Tone mapping control also shows ACES and Linear, for comparison.
Build measurements
- Triangles
- 10,568
- Estimated draws
- 330
- Materials
- 11
- Textures
- 0
- Animation clips
- 0
- Bounds X × Y × Z
- 48.65 × 38.23 × 22 m
- Build warnings
- 0
Measurements come from this build.
Download this build
Runtime: 158,776 bytes. Original: 158,548 bytes.
These GLBs are build outputs of the MIT-licensed example source; no separate terms are stated for the builds.
Runtime provenance metadataSHA-256 download hashes
- Runtime GLB
- 0ac829263b7ce2573cbbc47b6fd18e9b6ff259eea492f7a115baab787f75c1f0
- Original GLB
- 2906d7a2a81d650c76eb576785b5397b7e961f55e6a550fa1a998bac88f7f8e7
- Source
- 0aa97fb40d1e35a3b12a33908d885fc461978975af9d3a5314f9ae784486aff8
The example source is part of the Kiln repository. Repository licence: MIT.
These GLBs are build outputs of the MIT-licensed example source; no separate terms are stated for the builds.
Recorded authorship
Gemini 3.8 Flash through Antigravity CLI (agy)
Source-header credit
- Source access
- Source header declares no repository implementation or finished examples supplied
- Inherited context
- Not independently recorded; source-header declarations only
- Starting example
- None supplied, according to source header
- Human input
- Header declares no hand-authored source; other intervention not recorded
- Authoring review
- Six-view review declared; renderer fidelity not recorded
Gallery GPU render of this exact source. Source, artifact, image hashes and camera settings are recorded alongside the poster; the artifact hash names the GLB bytes the image was rendered from, which the downloadable rebuild reproduces byte for byte only on the platform that recorded it.
Poster camera and render recordThe source behind this build
// Authored by: gemini-3.8-flash-high, via agy.
//
// Written by the model itself through the Kiln MCP tools: it wrote the
// program, rendered it, looked at its own six-view contact sheet, and
// revised. Not a line of it is hand-authored.
//
// Dispatched into a clean directory containing only the brief and the Kiln
// skills, with no access to this repository or to any finished example.

const meta = { name: 'HarbourCrane', category: 'prop' };

function build() {
  const root = createRoot('HarbourCrane');

  // ==========================================
  // MATERIALS (Authentic Maritime Container Terminal PBR)
  // ==========================================
  const craneOrange  = gameMaterial(0xd34218, { roughness: 0.45, metalness: 0.25 });
  const craneWhite   = gameMaterial(0xf2f4f7, { roughness: 0.35, metalness: 0.15 });
  const darkSteel    = gameMaterial(0x24272d, { roughness: 0.55, metalness: 0.75 });
  const hazardYellow = gameMaterial(0xf6b200, { roughness: 0.4, metalness: 0.2 });
  const railingYellow= gameMaterial(0xebb312, { roughness: 0.5, metalness: 0.2 });
  const cableSteel   = gameMaterial(0x18191c, { roughness: 0.7, metalness: 0.85 });
  const concreteGrey = gameMaterial(0x5f636a, { roughness: 0.9, metalness: 0.05 });
  const glass        = glassMaterial(0x7dc2e8, { opacity: 0.45, roughness: 0.1, metalness: 0.1 });
  const cabInterior  = gameMaterial(0x1a1c20, { roughness: 0.8, metalness: 0.2 });
  const warningLight = gameMaterial(0xee1100, { roughness: 0.3, emissive: 0xee1100, emissiveIntensity: 0.9 });
  const statusGreen  = gameMaterial(0x22cc44, { roughness: 0.4, emissive: 0x11aa22, emissiveIntensity: 0.8 });

  // ==========================================
  // KEY DIMENSIONS & COORDINATES
  // +X forward (waterside outreach over docked container ship)
  // +Y up (ground dock rail level at Y = 0.0)
  // +Z asset right (quay wall & crane travel rails run along Z)
  // ==========================================
  const legX_WS = 7.0;     // Waterside legs at X = +7.0
  const legX_LS = -7.0;    // Landside legs at X = -7.0
  const legSpanZ = 7.5;    // Half-width along dock track: legs at Z = +/-7.5 (15m wheelbase along track)
  const portalH = 16.0;    // Clearance height for container trucks/trains driving along Z
  const boomH = 25.5;      // Main girder rail level
  const apexH = 37.0;      // Pylon apex sheave height

  // ==========================================
  // 1. DOCK RAILS & BOGIES (Grounding on Y=0)
  // Two ground crane rails embedded in dock at Y=0.0
  // ==========================================
  const railLengthZ = 22.0;
  const railHeight = 0.35;
  const railWidth = 0.30;
  const railGeo = boxGeo(railWidth, railHeight, railLengthZ);

  // Waterside and Landside crane rails sitting exactly on Y=0
  createPart('Rail_Waterside', railGeo, darkSteel, { position: [legX_WS, railHeight * 0.5, 0], parent: root });
  createPart('Rail_Landside',  railGeo, darkSteel, { position: [legX_LS, railHeight * 0.5, 0], parent: root });

  // Sill Beams along Z connecting the bogies on each rail
  const sillBeamLength = legSpanZ * 2 + 3.0; // 18m
  const sillBeamGeo = boxGeo(0.9, 0.9, sillBeamLength);
  createPart('SillBeam_Waterside', sillBeamGeo, craneOrange, { position: [legX_WS, 1.35, 0], parent: root });
  createPart('SillBeam_Landside',  sillBeamGeo, craneOrange, { position: [legX_LS, 1.35, 0], parent: root });

  // Bogie Assemblies at 4 corners
  // Wheels roll along Z: wheel axis is along X (cylinderXGeo)
  const wheelRadius = 0.40;
  const wheelY = railHeight + wheelRadius * 0.85; // tread rests on rail
  const wheelGeo = cylinderXGeo(wheelRadius, wheelRadius, 0.28, 12);
  const flangeGeo = cylinderXGeo(wheelRadius + 0.06, wheelRadius + 0.06, 0.05, 12);
  const subTruckGeo = boxGeo(0.7, 0.5, 2.2);
  const rockerGeo = boxGeo(0.8, 0.65, 3.8);
  const bogiePivotGeo = cylinderYGeo(0.45, 0.45, 0.8, 12);
  const railScraperGeo = boxGeo(0.45, 0.3, 0.35);

  const bogieCorners = [
    { name: 'WS_R', x: legX_WS, z: legSpanZ },
    { name: 'WS_L', x: legX_WS, z: -legSpanZ },
    { name: 'LS_R', x: legX_LS, z: legSpanZ },
    { name: 'LS_L', x: legX_LS, z: -legSpanZ },
  ];

  bogieCorners.forEach((c) => {
    // Central equalizer rocker
    createPart(`Rocker_${c.name}`, rockerGeo, darkSteel, { position: [c.x, 0.95, c.z], parent: root });
    createPart(`Pivot_${c.name}`, bogiePivotGeo, darkSteel, { position: [c.x, 1.35, c.z], parent: root });

    // Two 2-wheel sub-trucks per corner = 4 wheels per corner = 16 wheels total
    [-1.15, 1.15].forEach((dz, tIdx) => {
      const tz = c.z + dz;
      createPart(`Truck_${c.name}_${tIdx}`, subTruckGeo, darkSteel, { position: [c.x, 0.6, tz], parent: root });

      // Wheels
      [-0.6, 0.6].forEach((wz, wIdx) => {
        const posZ = tz + wz;
        createPart(`Wheel_${c.name}_${tIdx}_${wIdx}`, wheelGeo, darkSteel, { position: [c.x, wheelY, posZ], parent: root });
        // Wheel flange inside rail
        createPart(`Flange_${c.name}_${tIdx}_${wIdx}`, flangeGeo, darkSteel, { position: [c.x + (c.x > 0 ? -0.15 : 0.15), wheelY, posZ], parent: root });
      });

      // Rail safety scrapers / storm clamps
      createPart(`Scraper_${c.name}_${tIdx}`, railScraperGeo, hazardYellow, {
        position: [c.x, railHeight + 0.1, tz + (dz > 0 ? 1.05 : -1.05)],
        parent: root,
      });
    });
  });

  // Cable reel drum on the Landside-Right sill beam (trailing high-voltage cable)
  const reelDrumGeo = cylinderXGeo(1.3, 1.3, 0.9, 16);
  const reelCoreGeo = cylinderXGeo(0.55, 0.55, 1.0, 16);
  createPart('CableReelDrum', reelDrumGeo, hazardYellow, { position: [legX_LS - 0.75, 2.2, legSpanZ - 2.5], parent: root });
  createPart('CableReelCore', reelCoreGeo, darkSteel, { position: [legX_LS - 0.75, 2.2, legSpanZ - 2.5], parent: root });
  beamBetween('ReelBracket_A', [legX_LS, 1.35, legSpanZ - 2.5], [legX_LS - 0.75, 2.2, legSpanZ - 2.5], 0.09, darkSteel, { parent: root });
  beamBetween('ReelBracket_B', [legX_LS, 1.35, legSpanZ - 1.7], [legX_LS - 0.75, 2.2, legSpanZ - 2.5], 0.08, darkSteel, { parent: root });

  // ==========================================
  // 2. PORTAL TOWER & MASSIVE LEGS
  // 4 Legs: 2 Waterside legs at +X, 2 Landside legs at -X
  // Spanning across dock at portal deck Y = portalH
  // ==========================================
  const deckX = 4.6;
  const deckZ = 5.2;

  // 4 Heavy boxed legs
  const legNodes = [
    { id: 'WS_R', b: [legX_WS, 1.4, legSpanZ],   t: [deckX, portalH, deckZ] },
    { id: 'WS_L', b: [legX_WS, 1.4, -legSpanZ],  t: [deckX, portalH, -deckZ] },
    { id: 'LS_R', b: [legX_LS, 1.4, legSpanZ],   t: [-deckX, portalH, deckZ] },
    { id: 'LS_L', b: [legX_LS, 1.4, -legSpanZ],  t: [-deckX, portalH, -deckZ] },
  ];

  legNodes.forEach((leg) => {
    beamBetween(`Leg_${leg.id}`, leg.b, leg.t, 0.48, craneOrange, { parent: root });
  });

  // Waterside Portal Opening (at +X) and Landside Portal Opening (at -X)
  // Cross beam at portalH spanning between Left (-Z) and Right (+Z) legs
  const portalGantryBeamGeo = boxGeo(1.1, 1.5, deckZ * 2 + 1.4);
  createPart('PortalBeam_WS', portalGantryBeamGeo, craneOrange, { position: [deckX, portalH, 0], parent: root });
  createPart('PortalBeam_LS', portalGantryBeamGeo, craneOrange, { position: [-deckX, portalH, 0], parent: root });

  // Longitudinal tie beams connecting Waterside and Landside at portalH
  const portalSideTieGeo = boxGeo(deckX * 2, 1.1, 1.1);
  createPart('PortalSideTie_R', portalSideTieGeo, craneOrange, { position: [0, portalH, deckZ], parent: root });
  createPart('PortalSideTie_L', portalSideTieGeo, craneOrange, { position: [0, portalH, -deckZ], parent: root });

  // Side A-Frame Truss Bracing (between Waterside & Landside legs at +Z and -Z)
  [-1, 1].forEach((sZ) => {
    const sideName = sZ > 0 ? 'R' : 'L';
    const zBase = sZ * legSpanZ;
    const zTop = sZ * deckZ;
    const zMid = (zBase + zTop) * 0.5;
    const midH = 8.8;

    // Horizontal mid-strut
    beamBetween(`SideStrut_${sideName}`, [legX_WS * 0.72, midH, zMid], [legX_LS * 0.72, midH, zMid], 0.28, craneOrange, { parent: root });

    // Lower X-brace
    beamBetween(`SideX_Low1_${sideName}`, [legX_WS, 1.8, zBase], [legX_LS * 0.72, midH, zMid], 0.22, craneOrange, { parent: root });
    beamBetween(`SideX_Low2_${sideName}`, [legX_LS, 1.8, zBase], [legX_WS * 0.72, midH, zMid], 0.22, craneOrange, { parent: root });

    // Upper X-brace
    beamBetween(`SideX_Up1_${sideName}`, [legX_WS * 0.72, midH, zMid], [-deckX, portalH, zTop], 0.22, craneOrange, { parent: root });
    beamBetween(`SideX_Up2_${sideName}`, [legX_LS * 0.72, midH, zMid], [deckX, portalH, zTop], 0.22, craneOrange, { parent: root });
  });

  // Diagonal Knee Braces under Portal Cross Girders (arch clearance for container trucks)
  [-1, 1].forEach((sX) => {
    const pX = sX > 0 ? deckX : -deckX;
    [-1, 1].forEach((sZ) => {
      beamBetween(`KneeBrace_${sX > 0 ? 'WS' : 'LS'}_${sZ > 0 ? 'R' : 'L'}`,
        [pX, portalH - 0.7, sZ * (deckZ - 1.2)],
        [sX * (Math.abs(pX) + 0.8), portalH - 3.8, sZ * (deckZ + 0.4)],
        0.22, craneOrange, { parent: root });
    });
  });

  // Portal Deck Walkway Platform & Safety Handrails
  const portalDeckPlank = boxGeo(deckX * 2 + 0.8, 0.16, deckZ * 2 - 0.8);
  createPart('PortalDeck', portalDeckPlank, darkSteel, { position: [0, portalH + 0.65, 0], parent: root });

  // Portal Deck Handrails
  [-1, 1].forEach((sZ) => {
    const zR = sZ * (deckZ - 0.25);
    beamBetween(`PortalRailTop_${sZ > 0 ? 'R' : 'L'}`, [-deckX, portalH + 1.65, zR], [deckX, portalH + 1.65, zR], 0.035, railingYellow, { parent: root });
    beamBetween(`PortalRailMid_${sZ > 0 ? 'R' : 'L'}`, [-deckX, portalH + 1.15, zR], [deckX, portalH + 1.15, zR], 0.025, railingYellow, { parent: root });
    for (let x = -deckX + 0.6; x <= deckX - 0.4; x += 1.8) {
      beamBetween(`PortalRailPost_${sZ > 0 ? 'R' : 'L'}_${Math.round(x)}`, [x, portalH + 0.65, zR], [x, portalH + 1.65, zR], 0.035, railingYellow, { parent: root });
    }
  });

  // ==========================================
  // 3. UPPER TOWER & A-FRAME PYLON (APEX)
  // Columns rising from portal deck (Y=16) to boom level (Y=25.5)
  // and A-frame pylon up to apex (Y=37)
  // ==========================================
  const boomDeckX = 3.4;
  const boomDeckZ = 3.6;

  const towerCols = [
    { id: 'WS_R', b: [deckX, portalH, deckZ],   t: [boomDeckX, boomH, boomDeckZ] },
    { id: 'WS_L', b: [deckX, portalH, -deckZ],  t: [boomDeckX, boomH, -boomDeckZ] },
    { id: 'LS_R', b: [-deckX, portalH, deckZ],  t: [-boomDeckX, boomH, boomDeckZ] },
    { id: 'LS_L', b: [-deckX, portalH, -deckZ], t: [-boomDeckX, boomH, -boomDeckZ] },
  ];

  towerCols.forEach((col) => {
    beamBetween(`TowerCol_${col.id}`, col.b, col.t, 0.40, craneOrange, { parent: root });
  });

  // Upper Tower side diagonal bracing
  [-1, 1].forEach((sZ) => {
    const side = sZ > 0 ? 'R' : 'L';
    beamBetween(`TowerX1_${side}`, [deckX, portalH + 1.0, sZ * deckZ], [-boomDeckX, boomH - 0.2, sZ * boomDeckZ], 0.2, craneOrange, { parent: root });
    beamBetween(`TowerX2_${side}`, [-deckX, portalH + 1.0, sZ * deckZ], [boomDeckX, boomH - 0.2, sZ * boomDeckZ], 0.2, craneOrange, { parent: root });
  });

  // Upper boom support collar beams
  beamBetween('BoomCollar_WS', [boomDeckX, boomH, boomDeckZ], [boomDeckX, boomH, -boomDeckZ], 0.32, craneOrange, { parent: root });
  beamBetween('BoomCollar_LS', [-boomDeckX, boomH, boomDeckZ], [-boomDeckX, boomH, -boomDeckZ], 0.32, craneOrange, { parent: root });

  // A-Frame Pylon (Mast) rising above the boom to apexH (Y = 37.0)
  const apexX = 0.6;
  const apexZ = 1.4;

  beamBetween('Pylon_WS_R', [boomDeckX, boomH, boomDeckZ], [apexX, apexH, apexZ], 0.32, craneOrange, { parent: root });
  beamBetween('Pylon_WS_L', [boomDeckX, boomH, -boomDeckZ], [apexX, apexH, -apexZ], 0.32, craneOrange, { parent: root });
  beamBetween('Pylon_LS_R', [-boomDeckX, boomH, boomDeckZ], [apexX, apexH, apexZ], 0.32, craneOrange, { parent: root });
  beamBetween('Pylon_LS_L', [-boomDeckX, boomH, -boomDeckZ], [apexX, apexH, -apexZ], 0.32, craneOrange, { parent: root });

  // Apex Crosshead & Sheave Nest
  const apexCapGeo = boxGeo(1.8, 0.9, apexZ * 2 + 1.1);
  createPart('ApexCap', apexCapGeo, darkSteel, { position: [apexX, apexH + 0.35, 0], parent: root });

  const apexSheaveGeo = torusGeo(0.55, 0.08, 8, 16);
  createPart('ApexSheave_R', apexSheaveGeo, darkSteel, { position: [apexX, apexH + 0.6, apexZ], rotation: [0, 90, 0], parent: root });
  createPart('ApexSheave_L', apexSheaveGeo, darkSteel, { position: [apexX, apexH + 0.6, -apexZ], rotation: [0, 90, 0], parent: root });

  // Aircraft Warning Beacon at Apex (properly overlapping ApexCap)
  const beaconGeo = cylinderYGeo(0.14, 0.14, 0.45, 8);
  createPart('PylonBeacon', beaconGeo, warningLight, { position: [apexX, apexH + 0.85, 0], parent: root });

  // Pylon internal lacings
  const pylonMidH = (boomH + apexH) * 0.5;
  beamBetween('PylonMidStrut_R', [(boomDeckX + apexX) * 0.5, pylonMidH, (boomDeckZ + apexZ) * 0.5], [(-boomDeckX + apexX) * 0.5, pylonMidH, (boomDeckZ + apexZ) * 0.5], 0.18, craneOrange, { parent: root });
  beamBetween('PylonMidStrut_L', [(boomDeckX + apexX) * 0.5, pylonMidH, (-boomDeckZ - apexZ) * 0.5], [(-boomDeckX + apexX) * 0.5, pylonMidH, (-boomDeckZ - apexZ) * 0.5], 0.18, craneOrange, { parent: root });
  beamBetween('PylonMidTie', [(boomDeckX + apexX) * 0.5, pylonMidH, (boomDeckZ + apexZ) * 0.5], [(boomDeckX + apexX) * 0.5, pylonMidH, (-boomDeckZ - apexZ) * 0.5], 0.18, craneOrange, { parent: root });

  // ==========================================
  // 4. MAIN CANTILEVER BOOM & COUNTERWEIGHT BOOM
  // Reaching out along +X over the water (outreach tip at X = +33.0)
  // Counterweight boom reaching behind along -X (tip at X = -15.5)
  // Twin box girders at Z = +/-1.85
  // ==========================================
  const boomTipX = 33.0;
  const boomRearX = -15.5;
  const boomLength = boomTipX - boomRearX; // 48.5m
  const boomCenterX = (boomTipX + boomRearX) * 0.5; // 8.75m
  const girderZ = 1.85;
  const girderWidth = 0.65;
  const girderHeight = 2.3;

  // Twin main girders
  const girderGeo = boxGeo(boomLength, girderHeight, girderWidth);
  createPart('Girder_R', girderGeo, craneOrange, { position: [boomCenterX, boomH + 1.15, girderZ], parent: root });
  createPart('Girder_L', girderGeo, craneOrange, { position: [boomCenterX, boomH + 1.15, -girderZ], parent: root });

  // Trolley running rails underneath girders (Y = boomH - 0.05)
  const trolleyRailGeo = boxGeo(boomLength - 3.5, 0.14, 0.18);
  createPart('TrolleyRail_R', trolleyRailGeo, darkSteel, { position: [boomCenterX + 1.6, boomH - 0.05, girderZ], parent: root });
  createPart('TrolleyRail_L', trolleyRailGeo, darkSteel, { position: [boomCenterX + 1.6, boomH - 0.05, -girderZ], parent: root });

  // Transverse diaphragms connecting the twin girders
  const diaphragmGeo = boxGeo(0.4, 1.9, girderZ * 2 - girderWidth);
  for (let x = -13.5; x <= 31.0; x += 3.5) {
    createPart(`Diaphragm_${Math.round(x)}`, diaphragmGeo, craneOrange, { position: [x, boomH + 1.15, 0], parent: root });
  }

  // Boom maintenance catwalk & decking
  const walkwayGeo = boxGeo(boomLength - 0.8, 0.12, girderZ * 2 - girderWidth);
  createPart('BoomWalkway', walkwayGeo, darkSteel, { position: [boomCenterX, boomH + 2.32, 0], parent: root });

  // Boom yellow safety handrails along both outer girder edges
  [-1, 1].forEach((sZ) => {
    const zRail = sZ * (girderZ + 0.38);
    beamBetween(`BoomRailTop_${sZ > 0 ? 'R' : 'L'}`, [boomRearX + 0.6, boomH + 3.35, zRail], [boomTipX - 0.6, boomH + 3.35, zRail], 0.035, railingYellow, { parent: root });
    beamBetween(`BoomRailMid_${sZ > 0 ? 'R' : 'L'}`, [boomRearX + 0.6, boomH + 2.85, zRail], [boomTipX - 0.6, boomH + 2.85, zRail], 0.025, railingYellow, { parent: root });
    for (let x = boomRearX + 1.0; x <= boomTipX - 1.0; x += 3.2) {
      beamBetween(`BoomRailPost_${sZ > 0 ? 'R' : 'L'}_${Math.round(x)}`, [x, boomH + 2.32, zRail], [x, boomH + 3.35, zRail], 0.03, railingYellow, { parent: root });
    }
  });

  // Boom Tip Headblock & Buffers at X = boomTipX
  const boomTipHeadGeo = boxGeo(0.9, 1.8, girderZ * 2 + 1.3);
  createPart('BoomTipHead', boomTipHeadGeo, darkSteel, { position: [boomTipX - 0.3, boomH + 1.15, 0], parent: root });

  // Warning light at boom tip (overlapping BoomTipHead top at boomH + 2.05)
  createPart('TipBeacon', beaconGeo, warningLight, { position: [boomTipX - 0.3, boomH + 2.15, 0], parent: root });

  // Floodlight array at boom tip pointing down toward cargo ships
  const floodlightBarGeo = boxGeo(0.25, 0.35, 3.4);
  createPart('FloodlightBar', floodlightBarGeo, darkSteel, { position: [boomTipX - 0.7, boomH - 0.25, 0], parent: root });
  // Rigid floodlight mounting brackets connecting to BoomTipHead
  beamBetween('LightMount_R', [boomTipX - 0.3, boomH + 0.3, 1.2], [boomTipX - 0.7, boomH - 0.25, 1.2], 0.06, darkSteel, { parent: root });
  beamBetween('LightMount_L', [boomTipX - 0.3, boomH + 0.3, -1.2], [boomTipX - 0.7, boomH - 0.25, -1.2], 0.06, darkSteel, { parent: root });

  [-1.2, 0, 1.2].forEach((zL, i) => {
    const lightHousingGeo = boxGeo(0.5, 0.45, 0.55);
    createPart(`FloodHousing_${i}`, lightHousingGeo, craneWhite, { position: [boomTipX - 0.7, boomH - 0.6, zL], parent: root });
    const lensGeo = cylinderXGeo(0.2, 0.2, 0.05, 12);
    createPart(`FloodLens_${i}`, lensGeo, glass, { position: [boomTipX - 0.44, boomH - 0.6, zL], parent: root });
  });

  // ==========================================
  // 5. TENSION STAYS (FORESTAYS & BACKSTAYS)
  // Structural pin-ended tension tie bars
  // ==========================================
  // Outer forestays to outreach tip (X = 27.0)
  beamBetween('Stay_Outer_R', [apexX, apexH + 0.5, apexZ], [27.0, boomH + 2.3, girderZ], 0.09, cableSteel, { parent: root });
  beamBetween('Stay_Outer_L', [apexX, apexH + 0.5, -apexZ], [27.0, boomH + 2.3, -girderZ], 0.09, cableSteel, { parent: root });

  // Inner forestays to mid boom (X = 14.5)
  beamBetween('Stay_Inner_R', [apexX, apexH + 0.4, apexZ], [14.5, boomH + 2.3, girderZ], 0.08, cableSteel, { parent: root });
  beamBetween('Stay_Inner_L', [apexX, apexH + 0.4, -apexZ], [14.5, boomH + 2.3, -girderZ], 0.08, cableSteel, { parent: root });

  // Rear backstays to counterweight boom (X = -14.0)
  beamBetween('Backstay_Main_R', [apexX, apexH + 0.5, apexZ], [-14.0, boomH + 2.3, girderZ], 0.09, cableSteel, { parent: root });
  beamBetween('Backstay_Main_L', [apexX, apexH + 0.5, -apexZ], [-14.0, boomH + 2.3, -girderZ], 0.09, cableSteel, { parent: root });

  // ==========================================
  // 6. MACHINE HOUSE & COUNTERWEIGHT
  // ==========================================
  // Machine House sits on rear boom deck (X = -4.8 to -11.4)
  const mhLength = 6.6;
  const mhWidth = 4.5;
  const mhHeight = 3.5;
  const mhGeo = boxGeo(mhLength, mhHeight, mhWidth);
  createPart('MachineHouse', mhGeo, craneWhite, { position: [-8.1, boomH + 2.32 + mhHeight * 0.5, 0], parent: root });

  // Machine house roof louvers & HVAC
  const hvacGeo = boxGeo(1.6, 0.8, 1.8);
  createPart('HVAC_Pod', hvacGeo, darkSteel, { position: [-6.8, boomH + 2.32 + mhHeight + 0.4, 0.9], parent: root });
  const ventCowlGeo = cylinderYGeo(0.38, 0.42, 0.6, 12);
  createPart('VentCowl', ventCowlGeo, darkSteel, { position: [-9.5, boomH + 2.32 + mhHeight + 0.3, -1.1], parent: root });

  // Service access doors
  const mhDoorGeo = boxGeo(0.1, 2.2, 1.1);
  createPart('MH_Door', mhDoorGeo, darkSteel, { position: [-4.75, boomH + 3.42, 0], parent: root });

  // Machine house roof maintenance jib crane
  const jibMastGeo = cylinderYGeo(0.12, 0.12, 1.9, 8);
  createPart('JibMast', jibMastGeo, hazardYellow, { position: [-10.8, boomH + 2.32 + mhHeight + 0.95, 1.3], parent: root });
  beamBetween('JibArm', [-10.8, boomH + 2.32 + mhHeight + 1.8, 1.3], [-7.8, boomH + 2.32 + mhHeight + 1.8, 1.3], 0.08, hazardYellow, { parent: root });
  beamBetween('JibStay', [-10.8, boomH + 2.32 + mhHeight + 1.8, 1.3], [-9.0, boomH + 2.32 + mhHeight + 1.2, 1.3], 0.05, cableSteel, { parent: root });

  // Machine house roof safety handrails (with vertical posts fully anchoring to roof)
  const mhTopY = boomH + 2.32 + mhHeight;
  [-1, 1].forEach((sZ) => {
    const zE = sZ * (mhWidth * 0.5 - 0.12);
    beamBetween(`MHRailTop_${sZ > 0 ? 'R' : 'L'}`, [-8.1 - mhLength * 0.5 + 0.2, mhTopY + 1.0, zE], [-8.1 + mhLength * 0.5 - 0.2, mhTopY + 1.0, zE], 0.03, railingYellow, { parent: root });
    beamBetween(`MHRailMid_${sZ > 0 ? 'R' : 'L'}`, [-8.1 - mhLength * 0.5 + 0.2, mhTopY + 0.5, zE], [-8.1 + mhLength * 0.5 - 0.2, mhTopY + 0.5, zE], 0.02, railingYellow, { parent: root });
    for (let x = -8.1 - mhLength * 0.5 + 0.3; x <= -8.1 + mhLength * 0.5 - 0.1; x += 1.6) {
      beamBetween(`MHRailPost_${sZ > 0 ? 'R' : 'L'}_${Math.round(x)}`, [x, mhTopY - 0.05, zE], [x, mhTopY + 1.0, zE], 0.03, railingYellow, { parent: root });
    }
  });

  // End rail at back of machine house roof
  const mhRearX = -8.1 - mhLength * 0.5 + 0.2;
  beamBetween('MHRailEndTop', [mhRearX, mhTopY + 1.0, -mhWidth * 0.5 + 0.12], [mhRearX, mhTopY + 1.0, mhWidth * 0.5 - 0.12], 0.03, railingYellow, { parent: root });
  beamBetween('MHRailEndMid', [mhRearX, mhTopY + 0.5, -mhWidth * 0.5 + 0.12], [mhRearX, mhTopY + 0.5, mhWidth * 0.5 - 0.12], 0.02, railingYellow, { parent: root });

  // Counterweight Blocks at rear boom tip (X = -13.2 to -15.5)
  const cwFrameGeo = boxGeo(2.6, 2.5, 4.4);
  createPart('CounterweightCradle', cwFrameGeo, darkSteel, { position: [-14.2, boomH + 1.25, 0], parent: root });
  const ballastBlockGeo = boxGeo(2.2, 2.1, 4.0);
  createPart('BallastBlock', ballastBlockGeo, concreteGrey, { position: [-14.2, boomH + 1.25, 0], parent: root });

  // ==========================================
  // 7. TROLLEY & OPERATOR CAB
  // Positioned out over the water at X = 18.0
  // ==========================================
  const trolleyX = 18.0;
  const trolleyY = boomH - 0.35; // overlaps bottom of rails

  // Trolley chassis
  const trolleyChassisGeo = boxGeo(4.4, 0.7, 4.3);
  createPart('TrolleyChassis', trolleyChassisGeo, craneOrange, { position: [trolleyX, trolleyY, 0], parent: root });

  // 4 Trolley wheel bogies engaging the boom rails
  [-1.6, 1.6].forEach((dx, idx) => {
    [-girderZ, girderZ].forEach((gz, sideIdx) => {
      const tWheel = cylinderZGeo(0.26, 0.26, 0.22, 12);
      createPart(`TrolleyWheel_${idx}_${sideIdx}`, tWheel, darkSteel, { position: [trolleyX + dx, boomH + 0.05, gz], parent: root });
      const tBracket = boxGeo(0.65, 0.45, 0.28);
      createPart(`TrolleyBracket_${idx}_${sideIdx}`, tBracket, darkSteel, { position: [trolleyX + dx, boomH - 0.15, gz], parent: root });
    });
  });

  // Hoist winch drums & drive motor housings on trolley
  const winchDrumGeo = cylinderXGeo(0.48, 0.48, 1.8, 16);
  createPart('WinchDrum_R', winchDrumGeo, darkSteel, { position: [trolleyX, trolleyY + 0.65, 1.0], parent: root });
  createPart('WinchDrum_L', winchDrumGeo, darkSteel, { position: [trolleyX, trolleyY + 0.65, -1.0], parent: root });

  const motorBoxGeo = boxGeo(1.3, 0.75, 1.1);
  createPart('HoistMotor_F', motorBoxGeo, darkSteel, { position: [trolleyX + 1.4, trolleyY + 0.6, 0], parent: root });
  createPart('HoistMotor_R', motorBoxGeo, darkSteel, { position: [trolleyX - 1.4, trolleyY + 0.6, 0], parent: root });

  // Operator Cab suspended underneath front-left of trolley
  const cabX = trolleyX + 1.2;
  const cabY = trolleyY - 1.85;
  const cabZ = 1.1; // offset so operator looks directly down at container spread

  // Cab rigid steel suspension arms
  beamBetween('CabHanger_1', [cabX - 0.85, trolleyY - 0.35, cabZ - 0.75], [cabX - 0.85, cabY + 1.15, cabZ - 0.75], 0.06, darkSteel, { parent: root });
  beamBetween('CabHanger_2', [cabX + 0.85, trolleyY - 0.35, cabZ - 0.75], [cabX + 0.85, cabY + 1.15, cabZ - 0.75], 0.06, darkSteel, { parent: root });
  beamBetween('CabHanger_3', [cabX - 0.85, trolleyY - 0.35, cabZ + 0.75], [cabX - 0.85, cabY + 1.15, cabZ + 0.75], 0.06, darkSteel, { parent: root });
  beamBetween('CabHanger_4', [cabX + 0.85, trolleyY - 0.35, cabZ + 0.75], [cabX + 0.85, cabY + 1.15, cabZ + 0.75], 0.06, darkSteel, { parent: root });

  // Cab body
  const cabBodyGeo = boxGeo(2.5, 2.1, 2.0);
  createPart('CabBody', cabBodyGeo, craneWhite, { position: [cabX, cabY, cabZ], parent: root });

  // Panoramic Glazing: forward window, downward observation bay, side windows
  const cabFrontWin = boxGeo(0.1, 1.15, 1.7);
  createPart('CabWin_Front', cabFrontWin, glass, { position: [cabX + 1.26, cabY + 0.35, cabZ], parent: root });

  // Downward floor observation window
  const cabDownWin = boxGeo(0.1, 0.75, 1.5);
  createPart('CabWin_Down', cabDownWin, glass, { position: [cabX + 1.2, cabY - 0.65, cabZ], rotation: [0, 0, 30], parent: root });

  // Side windows
  const cabSideWin = boxGeo(1.5, 1.05, 0.1);
  createPart('CabWin_SideR', cabSideWin, glass, { position: [cabX + 0.3, cabY + 0.35, cabZ + 1.01], parent: root });
  createPart('CabWin_SideL', cabSideWin, glass, { position: [cabX + 0.3, cabY + 0.35, cabZ - 1.01], parent: root });

  // Interior operator seat and dual console joysticks
  const seatGeo = boxGeo(0.65, 0.75, 0.65);
  createPart('OperatorSeat', seatGeo, cabInterior, { position: [cabX + 0.2, cabY - 0.2, cabZ], parent: root });
  const consoleGeo = boxGeo(0.45, 0.65, 0.85);
  createPart('OperatorConsole', consoleGeo, darkSteel, { position: [cabX + 0.85, cabY - 0.3, cabZ], parent: root });

  // ==========================================
  // 8. SPREADER & WIRE HOIST RIGGING
  // Spreader length (40ft = ~9.2m) is ALONG Z (parallel to dock & ship holds)!
  // Spreader width is ALONG X (~2.44m standard container width)
  // ==========================================
  const spreaderY = 9.2;
  const headblockY = spreaderY + 1.45;

  // Headblock (sheave carrier between cables and spreader)
  const headblockGeo = boxGeo(2.2, 0.7, 3.2);
  createPart('Headblock', headblockGeo, hazardYellow, { position: [trolleyX, headblockY, 0], parent: root });

  // 4 Hoist sheaves in headblock
  const hbSheaveGeo = torusGeo(0.38, 0.06, 8, 16);
  createPart('HbSheave_FR', hbSheaveGeo, darkSteel, { position: [trolleyX + 0.8, headblockY + 0.35, 1.1], rotation: [90, 0, 0], parent: root });
  createPart('HbSheave_FL', hbSheaveGeo, darkSteel, { position: [trolleyX + 0.8, headblockY + 0.35, -1.1], rotation: [90, 0, 0], parent: root });
  createPart('HbSheave_RR', hbSheaveGeo, darkSteel, { position: [trolleyX - 0.8, headblockY + 0.35, 1.1], rotation: [90, 0, 0], parent: root });
  createPart('HbSheave_RL', hbSheaveGeo, darkSteel, { position: [trolleyX - 0.8, headblockY + 0.35, -1.1], rotation: [90, 0, 0], parent: root });

  // 4 Main hoist steel cables (deeply overlapping trolley chassis and headblock)
  beamBetween('Cable_FR', [trolleyX + 0.8, trolleyY + 0.2, 1.1], [trolleyX + 0.8, headblockY - 0.1, 1.1], 0.038, cableSteel, { parent: root });
  beamBetween('Cable_FL', [trolleyX + 0.8, trolleyY + 0.2, -1.1], [trolleyX + 0.8, headblockY - 0.1, -1.1], 0.038, cableSteel, { parent: root });
  beamBetween('Cable_RR', [trolleyX - 0.8, trolleyY + 0.2, 1.1], [trolleyX - 0.8, headblockY - 0.1, 1.1], 0.038, cableSteel, { parent: root });
  beamBetween('Cable_RL', [trolleyX - 0.8, trolleyY + 0.2, -1.1], [trolleyX - 0.8, headblockY - 0.1, -1.1], 0.038, cableSteel, { parent: root });

  // Twistlock adapter pins connecting headblock to spreader frame
  [-0.7, 0.7].forEach((hx, hIdx) => {
    [-1.0, 1.0].forEach((hz, zIdx) => {
      beamBetween(`HbPin_${hIdx}_${zIdx}`, [trolleyX + hx, headblockY + 0.1, hz], [trolleyX + hx, spreaderY + 0.4, hz], 0.08, darkSteel, { parent: root });
    });
  });

  // 40ft Telescopic Container Spreader Body
  // Length along Z = 9.2m, width along X = 2.44m, height = 0.65m
  const spreaderMainGeo = boxGeo(2.44, 0.65, 9.2);
  createPart('SpreaderMain', spreaderMainGeo, hazardYellow, { position: [trolleyX, spreaderY, 0], parent: root });

  // Spreader central hydraulic pack & tower
  const hydrPackGeo = boxGeo(1.6, 0.85, 2.4);
  createPart('SpreaderHydraulics', hydrPackGeo, darkSteel, { position: [trolleyX, spreaderY + 0.55, 0], parent: root });

  // Telescoping end beams at Z = +/-4.6
  [-1, 1].forEach((sEnd) => {
    const endZ = sEnd * 4.6;
    const endBeamGeo = boxGeo(2.5, 0.8, 0.6);
    createPart(`SpreaderEnd_${sEnd > 0 ? 'R' : 'L'}`, endBeamGeo, hazardYellow, { position: [trolleyX, spreaderY, endZ], parent: root });

    // 4 Corner flippers (angled guide flippers for centering onto containers)
    [-1, 1].forEach((sX) => {
      const flipX = trolleyX + sX * 1.25;
      const flipperGeo = boxGeo(0.35, 0.95, 0.12);
      createPart(`Flipper_${sEnd > 0 ? 'R' : 'L'}_${sX > 0 ? 'F' : 'R'}`, flipperGeo, hazardYellow, {
        position: [flipX, spreaderY - 0.35, endZ + sEnd * 0.2],
        rotation: [sEnd * 25, 0, 0],
        parent: root,
      });

      // Twistlock pins at corner
      const twistlockGeo = cylinderYGeo(0.14, 0.14, 0.42, 8);
      createPart(`Twistlock_${sEnd > 0 ? 'R' : 'L'}_${sX > 0 ? 'F' : 'R'}`, twistlockGeo, darkSteel, {
        position: [flipX - sX * 0.15, spreaderY - 0.45, endZ],
        parent: root,
      });

      // Twistlock status indicator light
      const statusLightGeo = cylinderYGeo(0.06, 0.06, 0.12, 6);
      createPart(`StatusLight_${sEnd > 0 ? 'R' : 'L'}_${sX > 0 ? 'F' : 'R'}`, statusLightGeo, statusGreen, {
        position: [flipX - sX * 0.15, spreaderY + 0.45, endZ],
        parent: root,
      });
    });
  });

  // ==========================================
  // 9. ACCESS LADDERS & CATWALKS
  // ==========================================
  // Lower caged ladder on Landside-Right leg from dock rail level (Y=1.4) to mid landing (Y=8.8)
  createLadder('LegLadder_Lower', {
    bottom: [legX_LS * 0.95, 1.4, legSpanZ + 0.45],
    top: [legX_LS * 0.72, 8.8, (legSpanZ + deckZ) * 0.5 + 0.45],
    width: 0.5,
    rungCount: 16,
    material: railingYellow,
    parent: root,
  });

  // Mid landing platform at Y = 8.8
  const midLandingGeo = boxGeo(1.4, 0.12, 1.4);
  createPart('MidLanding_LS_R', midLandingGeo, darkSteel, { position: [legX_LS * 0.72, 8.8, (legSpanZ + deckZ) * 0.5 + 0.55], parent: root });

  // Upper ladder from mid landing (Y=8.8) to portal deck (Y=portalH)
  createLadder('LegLadder_Upper', {
    bottom: [legX_LS * 0.72, 8.8, (legSpanZ + deckZ) * 0.5 + 0.45],
    top: [-deckX - 0.1, portalH, deckZ + 0.45],
    width: 0.5,
    rungCount: 16,
    material: railingYellow,
    parent: root,
  });

  // Tower ladder from portal deck (Y=portalH) to boom level (Y=boomH)
  createLadder('TowerLadder', {
    bottom: [-deckX + 0.2, portalH + 0.65, deckZ - 0.2],
    top: [-boomDeckX + 0.2, boomH + 1.0, boomDeckZ - 0.2],
    width: 0.5,
    rungCount: 18,
    material: railingYellow,
    parent: root,
  });

  // Access stairs leading from rear boom deck into Machine House
  createLadder('MHLadder', {
    bottom: [-boomDeckX, boomH + 1.15, 0],
    top: [-4.75, boomH + 2.32, 0],
    width: 0.8,
    rungCount: 4,
    material: railingYellow,
    parent: root,
  });

  return root;
}Scroll code horizontally
Brief and retained revisions
No brief or earlier revisions are recorded. The source download contains the version built for this page.