Deep-sea station
Demo run
Earlier examples from earlier Kiln versions.
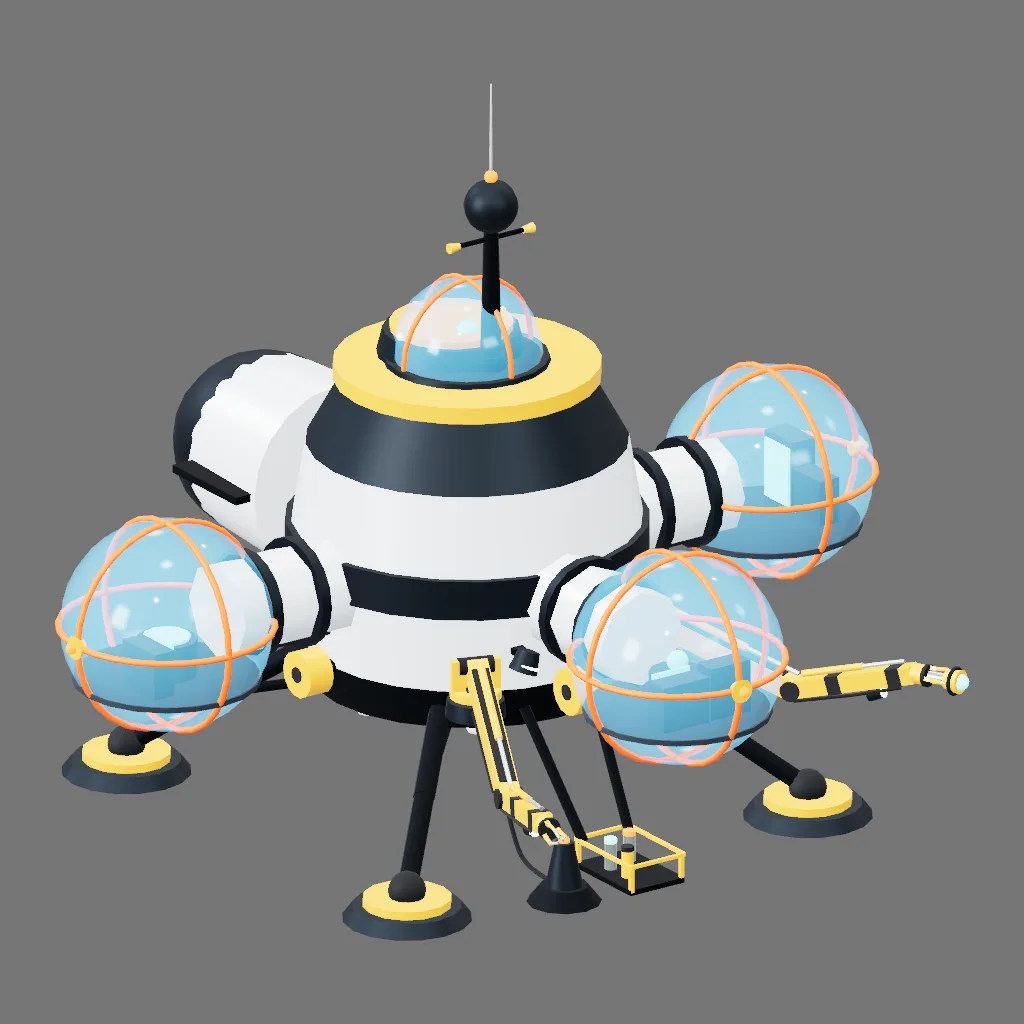
Drag to orbit after opening. The model starts stationary.
For your engine. The download is a standard glTF 2.0 binary (GLB) with PBR metallic-roughness materials. Optional extensions declared by this file: KHR_materials_emissive_strength. Importer support varies; see the Blender and Unity guide. glTF stores materials, not lighting or tone mapping, so your engine decides how they read. This 3D view tone-maps with Review Neutral, the Khronos PBR Neutral construction with a smaller glare offset (0.015 instead of 0.04), at exposure 0.9. Its Tone mapping control also shows ACES and Linear, for comparison.
Build measurements
- Triangles
- 22,808
- Estimated draws
- 230
- Materials
- 15
- Textures
- 0
- Animation clips
- 0
- Bounds X × Y × Z
- 13.52 × 11.2 × 14.14 m
- Build warnings
- 0
Measurements come from this build.
Download this build
Runtime: 347,088 bytes. Original: 346,852 bytes.
These GLBs are build outputs of the MIT-licensed example source; no separate terms are stated for the builds.
Runtime provenance metadataSHA-256 download hashes
- Runtime GLB
- 270119363cca7a04a29326ad05c55b52a2cd4ffa720bf7760acc105c4c11f97e
- Original GLB
- dca6606eee35d06e71aee3a80a92dcc6b9549aaa50a302bfb6dd8e986756dfec
- Source
- df6b76e688d9d5e6a23da05ed1fdac1a3d2975ca7f573ee00b0638e90edb27e8
The example source is part of the Kiln repository. Repository licence: MIT.
These GLBs are build outputs of the MIT-licensed example source; no separate terms are stated for the builds.
Recorded authorship
Gemini 3.8 Flash through Antigravity CLI (agy) ·
Recorded demo session; model credit supplied only where the retained run identifies it.
- Source access
- See retained demo run; no stronger isolation claim is made.
- Inherited context
- Not independently recorded; source-header declarations only
- Starting example
- Not recorded
- Human input
- Owner supplied direction; model-authored exported source preserved byte-for-byte.
- Authoring review
- Authoring feedback and shaded demo previews where available. Not a destination-runtime acceptance claim.
Gallery GPU render of this exact source. Source, artifact, image hashes and camera settings are recorded alongside the poster; the artifact hash names the GLB bytes the image was rendered from, which the downloadable rebuild reproduces byte for byte only on the platform that recorded it.
Poster camera and render recordThe source behind this build
const meta = {
  name: 'Deep-Sea Research Station',
  category: 'architecture',
  role: 'building'
};

function build() {
  const root = createRoot('DeepSeaStation');
  const d2r = (deg) => deg * Math.PI / 180;

  // --- Materials ---
  const hullWhite = gameMaterial(0xdce5ea, { roughness: 0.35, metalness: 0.3 });
  const hullDark = gameMaterial(0x1a232b, { roughness: 0.6, metalness: 0.7 });
  const frameworkDark = gameMaterial(0x12171d, { roughness: 0.7, metalness: 0.85 });
  const safetyYellow = gameMaterial(0xf4a900, { roughness: 0.35, metalness: 0.2 });
  const podFrameOrange = gameMaterial(0xf55a10, { roughness: 0.35, metalness: 0.2 });
  const jointBlack = gameMaterial(0x181a1e, { roughness: 0.8, metalness: 0.3 });
  const chromeMetal = gameMaterial(0xd4d8dc, { roughness: 0.15, metalness: 0.95 });
  const glass = glassMaterial(0x4dc0f5, { opacity: 0.32, roughness: 0.06, metalness: 0.1 });
  const floodLight = gameMaterial(0xffffff, { emissive: 0xffffff, emissiveIntensity: 3.5 });
  const cyanGlow = gameMaterial(0x00e5ff, { emissive: 0x00e5ff, emissiveIntensity: 2.5 });
  const amberBeacon = gameMaterial(0xff6600, { emissive: 0xff6600, emissiveIntensity: 2.2 });
  const interiorDeck = gameMaterial(0x242e38, { roughness: 0.85, metalness: 0.2 });
  const interiorPanel = gameMaterial(0x384754, { roughness: 0.5, metalness: 0.4 });
  const tankGas = gameMaterial(0xedf2f7, { roughness: 0.4, metalness: 0.2 });
  const tankStripe = gameMaterial(0x009e73, { roughness: 0.5, metalness: 0.2 });

  // ==========================================
  // 1. CENTRAL PRESSURE HULL & DOCKING CORE
  // ==========================================
  // Lower Machinery Ring
  createPart('Hull_LowerCollar', cylinderGeo(2.4, 2.3, 0.6, 24), frameworkDark, { position: [0, 2.2, 0], parent: root });
  createPart('Hull_MachineryBelt', cylinderGeo(2.5, 2.4, 1.2, 24), hullWhite, { position: [0, 3.1, 0], parent: root });

  // Mid Corridor Hub Belt
  createPart('Hull_MidBelt', cylinderGeo(2.65, 2.65, 0.6, 24), hullDark, { position: [0, 4.0, 0], parent: root });
  createPart('Hull_UpperSection', cylinderGeo(2.35, 2.55, 1.2, 24), hullWhite, { position: [0, 4.9, 0], parent: root });

  // Upper Taper & Observation Ring
  createPart('Hull_UpperTaper', cylinderGeo(1.8, 2.35, 1.0, 24), hullDark, { position: [0, 6.0, 0], parent: root });
  createPart('Hull_UpperDeckRim', cylinderGeo(1.95, 1.95, 0.25, 24), safetyYellow, { position: [0, 6.6, 0], parent: root });

  // Submersible Docking Hatch (Aft top)
  createPart('Docking_Collar', cylinderGeo(1.0, 1.1, 0.4, 18), hullDark, { position: [-0.4, 6.9, 0], parent: root });
  createPart('Docking_Hatch', cylinderGeo(0.9, 0.9, 0.1, 18), safetyYellow, { position: [-0.4, 7.15, 0], parent: root });
  createPart('Docking_LightFwd', sphereGeo(0.06, 8, 6), floodLight, { position: [0.5, 7.15, 0], parent: root });
  createPart('Docking_LightAft', sphereGeo(0.06, 8, 6), floodLight, { position: [-1.3, 7.15, 0], parent: root });
  createPart('Docking_LightStbd', sphereGeo(0.06, 8, 6), floodLight, { position: [-0.4, 7.15, 0.9], parent: root });
  createPart('Docking_LightPort', sphereGeo(0.06, 8, 6), floodLight, { position: [-0.4, 7.15, -0.9], parent: root });

  // Sensor & Communications Mast
  createPart('Mast_Base', cylinderGeo(0.2, 0.25, 0.3, 12), frameworkDark, { position: [0.6, 6.85, 0], parent: root });
  createPart('Mast_Pylon', cylinderGeo(0.1, 0.16, 2.2, 10), frameworkDark, { position: [0.6, 8.1, 0], parent: root });
  createPart('Mast_SonarDome', sphereGeo(0.4, 14, 10), hullDark, { position: [0.6, 9.3, 0], parent: root });
  createPart('Mast_AcousticBoom', cylinderGeo(0.04, 0.04, 1.3, 8), frameworkDark, { position: [0.6, 8.8, 0], rotation: [90, 0, 0], parent: root });
  createPart('Mast_TransducerL', cylinderGeo(0.08, 0.05, 0.18, 8), safetyYellow, { position: [0.6, 8.8, 0.65], rotation: [90, 0, 0], parent: root });
  createPart('Mast_TransducerR', cylinderGeo(0.08, 0.05, 0.18, 8), safetyYellow, { position: [0.6, 8.8, -0.65], rotation: [-90, 0, 0], parent: root });
  createPart('Mast_Beacon', sphereGeo(0.1, 10, 8), amberBeacon, { position: [0.6, 9.75, 0], parent: root });
  createPart('Mast_AntennaSpire', cylinderGeo(0.015, 0.03, 1.4, 6), chromeMetal, { position: [0.6, 10.5, 0], parent: root });

  // Aft Power Reactor / Engineering Pod (-X)
  createPart('Reactor_Corridor', cylinderGeo(0.7, 0.7, 1.2, 16), hullDark, { position: [-2.8, 3.8, 0], rotation: [0, 0, 90], parent: root });
  createPart('Reactor_Hull', cylinderGeo(1.35, 1.45, 1.8, 20), hullWhite, { position: [-4.2, 3.8, 0], rotation: [0, 0, 90], parent: root });
  createPart('Reactor_EndCap', sphereGeo(1.35, 16, 12), hullDark, { position: [-5.1, 3.8, 0], parent: root });
  createPart('Reactor_VaneTop', boxGeo(1.6, 0.4, 0.12), frameworkDark, { position: [-4.2, 4.7, 0], parent: root });
  createPart('Reactor_VaneStbd', boxGeo(1.6, 0.12, 0.4), frameworkDark, { position: [-4.2, 3.8, 1.5], parent: root });
  createPart('Reactor_VanePort', boxGeo(1.6, 0.12, 0.4), frameworkDark, { position: [-4.2, 3.8, -1.5], parent: root });

  // ==========================================
  // 2. SEAFLOOR ANCHORAGE & 4 LANDING LEGS
  // ==========================================
  const legAngles = [45, 135, 225, 315];
  for (let i = 0; i < 4; i++) {
    const deg = legAngles[i];
    const rad = d2r(deg);
    const cosA = Math.cos(rad);
    const sinA = Math.sin(rad);

    const fx = 5.0 * cosA;
    const fz = 5.0 * sinA;
    const fy = 0.1;

    const hx = 2.2 * cosA;
    const hz = 2.2 * sinA;
    const hy = 2.2;

    const prefix = 'Leg_' + deg;

    // Footpad resting on seabed (Y=0 to Y=0.2)
    createPart(prefix + '_Foot', cylinderGeo(0.8, 0.95, 0.2, 16), hullDark, { position: [fx, fy, fz], parent: root });
    createPart(prefix + '_BallastRing', cylinderGeo(0.65, 0.65, 0.15, 14), safetyYellow, { position: [fx, fy + 0.15, fz], parent: root });
    createPart(prefix + '_AnkleBall', sphereGeo(0.28, 12, 10), jointBlack, { position: [fx, fy + 0.32, fz], parent: root });

    // Telescoping heavy strut
    const midX = (fx + hx) * 0.5;
    const midY = (fy + 0.32 + hy) * 0.5;
    const midZ = (fz + hz) * 0.5;

    beamBetween(prefix + '_LowerStrut', [fx, fy + 0.32, fz], [midX, midY, midZ], 0.15, frameworkDark, { parent: root });
    beamBetween(prefix + '_ChromePiston', [fx * 0.4 + hx * 0.6, (fy + 0.32) * 0.4 + hy * 0.6, fz * 0.4 + hz * 0.6], [hx, hy, hz], 0.11, chromeMetal, { parent: root });
    beamBetween(prefix + '_UpperCollar', [midX, midY, midZ], [hx, hy, hz], 0.16, frameworkDark, { parent: root });

    // Diagonal knee brace to underbelly
    const kx = 0.8 * cosA;
    const kz = 0.8 * sinA;
    const ky = 1.9;
    beamBetween(prefix + '_KneeBrace', [midX, midY, midZ], [kx, ky, kz], 0.08, frameworkDark, { parent: root });
  }

  // Underside Gas / Life-Support Storage Tanks
  const tankAngles = [30, 90, 150, 210, 270, 330];
  for (let t = 0; t < tankAngles.length; t++) {
    const tRad = d2r(tankAngles[t]);
    const tx = 1.75 * Math.cos(tRad);
    const tz = 1.75 * Math.sin(tRad);
    createPart('Tank_' + t, capsuleGeo(0.22, 1.0, 8), tankGas, { position: [tx, 2.3, tz], parent: root });
    createPart('TankBand_' + t, cylinderGeo(0.23, 0.23, 0.25, 12), tankStripe, { position: [tx, 2.3, tz], parent: root });
    createPart('TankValve_' + t, cylinderGeo(0.07, 0.07, 0.12, 8), jointBlack, { position: [tx, 2.9, tz], parent: root });
  }

  // Maneuvering Station-Keeping Thrusters
  const thrusterAngles = [0, 90, 180, 270];
  for (let th = 0; th < 4; th++) {
    const a = d2r(thrusterAngles[th]);
    const thX = 2.8 * Math.cos(a);
    const thZ = 2.8 * Math.sin(a);
    const rotY = -thrusterAngles[th];

    beamBetween('ThPylon_' + th, [2.2 * Math.cos(a), 2.5, 2.2 * Math.sin(a)], [thX, 2.5, thZ], 0.12, frameworkDark, { parent: root });
    createPart('ThDuct_' + th, cylinderGeo(0.35, 0.35, 0.4, 14), safetyYellow, { position: [thX, 2.5, thZ], rotation: [90, rotY, 0], parent: root });
    createPart('ThCore_' + th, cylinderGeo(0.12, 0.12, 0.44, 10), jointBlack, { position: [thX, 2.5, thZ], rotation: [90, rotY, 0], parent: root });
  }

  // ==========================================
  // 3. GLASS HABITAT PODS WITH INTERIORS
  // ==========================================

  // Helper for Pod Corridors
  function buildCorridor(name, start, end) {
    beamBetween(name + '_Tube', start, end, 0.72, hullWhite, { parent: root });
    const mid = [(start[0] + end[0]) * 0.5, (start[1] + end[1]) * 0.5, (start[2] + end[2]) * 0.5];
    const dx = end[0] - start[0];
    const dz = end[2] - start[2];
    const angleY = Math.atan2(dz, dx) * 180 / Math.PI;

    createPart(name + '_Ring1', cylinderGeo(0.82, 0.82, 0.16, 18), hullDark, {
      position: [start[0] + dx * 0.35, start[1], start[2] + dz * 0.35],
      rotation: [0, -angleY, 90],
      parent: root
    });
    createPart(name + '_Ring2', cylinderGeo(0.82, 0.82, 0.16, 18), hullDark, {
      position: [start[0] + dx * 0.75, start[1], start[2] + dz * 0.75],
      rotation: [0, -angleY, 90],
      parent: root
    });

    // Subsea conduit piping along corridor underside
    const p1 = [start[0], start[1] - 0.75, start[2]];
    const p2 = [end[0], end[1] - 0.75, end[2]];
    const pipeGeo = pipeAlongPath([p1, p2], 0.05, { bendRadius: 0.1 });
    createPart(name + '_UnderPipe', pipeGeo, jointBlack, { parent: root });
  }

  // Pod 1: Forward Science / Deep Bio-Lab Pod
  buildCorridor('Corridor_Fwd', [2.3, 3.8, 0], [4.4, 3.8, 0]);
  const fwdPodCenter = [5.3, 3.8, 0];
  const podR = 1.55;

  // Glass Spheres
  createPart('Pod_Fwd_Glass', sphereGeo(podR, 24, 18), glass, { position: fwdPodCenter, parent: root });
  createPart('Pod_Fwd_EqFrame', torusGeo(podR + 0.02, 0.05, 8, 28), podFrameOrange, { position: fwdPodCenter, rotation: [90, 0, 0], parent: root });
  createPart('Pod_Fwd_MeridFrame1', torusGeo(podR + 0.02, 0.05, 8, 28), podFrameOrange, { position: fwdPodCenter, rotation: [0, 90, 0], parent: root });
  createPart('Pod_Fwd_MeridFrame2', torusGeo(podR + 0.02, 0.05, 8, 28), podFrameOrange, { position: fwdPodCenter, rotation: [0, 0, 0], parent: root });
  createPart('Pod_Fwd_NoseCap', cylinderGeo(0.18, 0.1, 0.16, 12), safetyYellow, { position: [fwdPodCenter[0] + podR, fwdPodCenter[1], fwdPodCenter[2]], rotation: [0, 0, -90], parent: root });
  createPart('Pod_Fwd_Beacon', sphereGeo(0.08, 8, 6), amberBeacon, { position: [fwdPodCenter[0] + podR + 0.14, fwdPodCenter[1], fwdPodCenter[2]], parent: root });

  // Forward Pod Interior
  createPart('Pod_Fwd_Floor', cylinderGeo(1.38, 1.38, 0.08, 20), interiorDeck, { position: [5.3, 3.0, 0], parent: root });
  createPart('Pod_Fwd_SpecimenTable', cylinderGeo(0.42, 0.42, 0.55, 12), interiorPanel, { position: [5.3, 3.32, 0], parent: root });
  createPart('Pod_Fwd_HoloSphere', sphereGeo(0.16, 12, 10), cyanGlow, { position: [5.3, 3.75, 0], parent: root });
  createPart('Pod_Fwd_ConsoleDesk', boxGeo(0.4, 0.7, 0.8), interiorPanel, { position: [5.9, 3.4, 0.4], parent: root });
  createPart('Pod_Fwd_ConsoleScreen', boxGeo(0.04, 0.35, 0.65), cyanGlow, { position: [5.7, 3.65, 0.4], parent: root });
  createPart('Pod_Fwd_Rack', boxGeo(0.35, 0.8, 0.7), interiorPanel, { position: [5.9, 3.45, -0.4], parent: root });

  // Pod 2: Starboard Habitat & Living Pod (+Z)
  buildCorridor('Corridor_Stbd', [0, 3.8, 2.3], [0, 3.8, 4.4]);
  const stbdPodCenter = [0, 3.8, 5.3];

  createPart('Pod_Stbd_Glass', sphereGeo(podR, 24, 18), glass, { position: stbdPodCenter, parent: root });
  createPart('Pod_Stbd_EqFrame', torusGeo(podR + 0.02, 0.05, 8, 28), podFrameOrange, { position: stbdPodCenter, rotation: [90, 0, 0], parent: root });
  createPart('Pod_Stbd_MeridFrame1', torusGeo(podR + 0.02, 0.05, 8, 28), podFrameOrange, { position: stbdPodCenter, rotation: [0, 0, 0], parent: root });
  createPart('Pod_Stbd_MeridFrame2', torusGeo(podR + 0.02, 0.05, 8, 28), podFrameOrange, { position: stbdPodCenter, rotation: [0, 90, 0], parent: root });
  createPart('Pod_Stbd_Cap', cylinderGeo(0.18, 0.1, 0.16, 12), safetyYellow, { position: [0, 3.8, 5.3 + podR], rotation: [90, 0, 0], parent: root });
  createPart('Pod_Stbd_Beacon', sphereGeo(0.08, 8, 6), amberBeacon, { position: [0, 3.8, 5.3 + podR + 0.14], parent: root });

  // Starboard Pod Interior
  createPart('Pod_Stbd_Floor', cylinderGeo(1.38, 1.38, 0.08, 20), interiorDeck, { position: [0, 3.0, 5.3], parent: root });
  createPart('Pod_Stbd_NavTable', cylinderGeo(0.45, 0.45, 0.55, 12), interiorPanel, { position: [0, 3.32, 5.3], parent: root });
  createPart('Pod_Stbd_NavDisplay', cylinderGeo(0.35, 0.35, 0.04, 12), cyanGlow, { position: [0, 3.62, 5.3], parent: root });
  createPart('Pod_Stbd_StationDesk', boxGeo(0.8, 0.7, 0.35), interiorPanel, { position: [0.4, 3.4, 5.9], parent: root });
  createPart('Pod_Stbd_StationScreen', boxGeo(0.65, 0.35, 0.04), cyanGlow, { position: [0.4, 3.65, 5.7], parent: root });

  // Pod 3: Port Oceanographic / Sensor Pod (-Z)
  buildCorridor('Corridor_Port', [0, 3.8, -2.3], [0, 3.8, -4.4]);
  const portPodCenter = [0, 3.8, -5.3];

  createPart('Pod_Port_Glass', sphereGeo(podR, 24, 18), glass, { position: portPodCenter, parent: root });
  createPart('Pod_Port_EqFrame', torusGeo(podR + 0.02, 0.05, 8, 28), podFrameOrange, { position: portPodCenter, rotation: [90, 0, 0], parent: root });
  createPart('Pod_Port_MeridFrame1', torusGeo(podR + 0.02, 0.05, 8, 28), podFrameOrange, { position: portPodCenter, rotation: [0, 0, 0], parent: root });
  createPart('Pod_Port_MeridFrame2', torusGeo(podR + 0.02, 0.05, 8, 28), podFrameOrange, { position: portPodCenter, rotation: [0, 90, 0], parent: root });
  createPart('Pod_Port_Cap', cylinderGeo(0.18, 0.1, 0.16, 12), safetyYellow, { position: [0, 3.8, -5.3 - podR], rotation: [-90, 0, 0], parent: root });
  createPart('Pod_Port_Beacon', sphereGeo(0.08, 8, 6), amberBeacon, { position: [0, 3.8, -5.3 - podR - 0.14], parent: root });

  // Port Pod Interior
  createPart('Pod_Port_Floor', cylinderGeo(1.38, 1.38, 0.08, 20), interiorDeck, { position: [0, 3.0, -5.3], parent: root });
  createPart('Pod_Port_Mainframe', boxGeo(0.7, 1.1, 0.4), interiorPanel, { position: [-0.3, 3.6, -5.9], parent: root });
  createPart('Pod_Port_ServerGlow', boxGeo(0.6, 0.9, 0.04), cyanGlow, { position: [-0.3, 3.6, -5.68], parent: root });
  createPart('Pod_Port_AnalysisDesk', boxGeo(0.8, 0.7, 0.35), interiorPanel, { position: [0.3, 3.4, -5.9], parent: root });

  // Pod 4: Top Command Vista Cupola
  createPart('Cupola_DeckRim', cylinderGeo(1.2, 1.25, 0.2, 20), hullDark, { position: [0, 6.7, 0], parent: root });
  createPart('Cupola_Glass', sphereGeo(1.1, 20, 14), glass, { position: [0, 6.85, 0], parent: root });
  createPart('Cupola_FrameArch1', torusGeo(1.12, 0.04, 8, 24), podFrameOrange, { position: [0, 6.85, 0], rotation: [0, 0, 0], parent: root });
  createPart('Cupola_FrameArch2', torusGeo(1.12, 0.04, 8, 24), podFrameOrange, { position: [0, 6.85, 0], rotation: [0, 90, 0], parent: root });
  createPart('Cupola_Floor', cylinderGeo(1.0, 1.0, 0.06, 18), interiorDeck, { position: [0, 6.75, 0], parent: root });
  createPart('Cupola_CommandOrb', sphereGeo(0.18, 12, 8), cyanGlow, { position: [0, 7.15, 0], parent: root });

  // ==========================================
  // 4. YELLOW ROBOTIC MANIPULATOR ARMS
  // ==========================================

  function buildArticulatedArm(armName, mountPos, yawDeg, pitch1Deg, pitch2Deg, pitch3Deg, rollDeg, gripClosed, hasScanner) {
    // 0. Reinforced Sponson Outrigger from Hull
    beamBetween(armName + '_Sponson', [2.1, 2.4, mountPos[2] * 0.65], mountPos, 0.18, frameworkDark, { parent: root });
    createPart(armName + '_BaseMount', cylinderGeo(0.42, 0.45, 0.25, 16), hullDark, {
      position: mountPos,
      parent: root
    });

    // 1. Shoulder Joint Pivot
    const shoulderPivot = createPivot(armName + '_ShoulderYaw', [mountPos[0], mountPos[1] + 0.16, mountPos[2]], root);
    shoulderPivot.rotation.y = d2r(yawDeg);

    // Turret Yoke & Rotary Table
    createPart(armName + '_YokeBase', cylinderGeo(0.38, 0.38, 0.12, 16), safetyYellow, {
      position: [0, 0.06, 0],
      parent: shoulderPivot
    });
    createPart(armName + '_YokeArmL', boxGeo(0.14, 0.55, 0.28), safetyYellow, {
      position: [0, 0.3, 0.22],
      parent: shoulderPivot
    });
    createPart(armName + '_YokeArmR', boxGeo(0.14, 0.55, 0.28), safetyYellow, {
      position: [0, 0.3, -0.22],
      parent: shoulderPivot
    });
    createPart(armName + '_ShoulderPin', cylinderGeo(0.13, 0.13, 0.52, 14), jointBlack, {
      position: [0, 0.48, 0],
      rotation: [90, 0, 0],
      parent: shoulderPivot
    });

    // 2. Shoulder Pitch Pivot
    const shoulderPitch = createPivot(armName + '_ShoulderPitch', [0, 0.48, 0], shoulderPivot);
    shoulderPitch.rotation.z = d2r(pitch1Deg);

    // Heavy Upper Arm Boom (length 2.3)
    const L1 = 2.3;
    createPart(armName + '_BoomMain', boxGeo(L1, 0.32, 0.3), safetyYellow, {
      position: [L1 * 0.5, 0, 0],
      parent: shoulderPitch
    });
    createPart(armName + '_BoomPlateT', boxGeo(L1 * 0.85, 0.04, 0.26), jointBlack, {
      position: [L1 * 0.5, 0.16, 0],
      parent: shoulderPitch
    });
    createPart(armName + '_BoomPlateB', boxGeo(L1 * 0.85, 0.04, 0.26), jointBlack, {
      position: [L1 * 0.5, -0.16, 0],
      parent: shoulderPitch
    });

    // Dual Hydraulic Lift Cylinders (Top and Bottom)
    createPart(armName + '_BoomHydrCylTop', cylinderGeo(0.06, 0.06, L1 * 0.55, 10), safetyYellow, {
      position: [L1 * 0.35, 0.24, 0],
      rotation: [0, 0, 90],
      parent: shoulderPitch
    });
    createPart(armName + '_BoomHydrRodTop', cylinderGeo(0.036, 0.036, L1 * 0.5, 10), chromeMetal, {
      position: [L1 * 0.75, 0.24, 0],
      rotation: [0, 0, 90],
      parent: shoulderPitch
    });

    // Hydraulic supply conduits along upper arm
    const upperHose = pipeAlongPath([[0, -0.22, 0.14], [L1 * 0.5, -0.24, 0.14], [L1 * 0.9, -0.22, 0.14]], 0.028, { bendRadius: 0.08 });
    createPart(armName + '_UpperHose', upperHose, jointBlack, { parent: shoulderPitch });

    // 3. Elbow Pitch Pivot
    const elbowPitch = createPivot(armName + '_ElbowPitch', [L1, 0, 0], shoulderPitch);
    elbowPitch.rotation.z = d2r(pitch2Deg);

    createPart(armName + '_ElbowHinge', cylinderGeo(0.15, 0.15, 0.38, 14), jointBlack, {
      position: [0, 0, 0],
      rotation: [90, 0, 0],
      parent: elbowPitch
    });

    // Forearm Boom (length 2.0)
    const L2 = 2.0;
    createPart(armName + '_ForearmMain', boxGeo(L2, 0.26, 0.26), safetyYellow, {
      position: [L2 * 0.5, 0, 0],
      parent: elbowPitch
    });
    // Hazard Stripes on forearm
    createPart(armName + '_HazardStripe1', boxGeo(0.22, 0.28, 0.28), jointBlack, {
      position: [L2 * 0.35, 0, 0],
      parent: elbowPitch
    });
    createPart(armName + '_HazardStripe2', boxGeo(0.22, 0.28, 0.28), jointBlack, {
      position: [L2 * 0.85, 0, 0],
      parent: elbowPitch
    });

    // Forearm Hydraulic Pitch Cylinder
    createPart(armName + '_ForeHydrCyl', cylinderGeo(0.05, 0.05, L2 * 0.5, 10), safetyYellow, {
      position: [L2 * 0.35, 0.2, 0],
      rotation: [0, 0, 90],
      parent: elbowPitch
    });
    createPart(armName + '_ForeHydrRod', cylinderGeo(0.03, 0.03, L2 * 0.45, 10), chromeMetal, {
      position: [L2 * 0.72, 0.2, 0],
      rotation: [0, 0, 90],
      parent: elbowPitch
    });

    // Flexible conduit hose on forearm
    const foreHose = pipeAlongPath([[0, -0.16, 0.12], [L2 * 0.5, -0.18, 0.12], [L2 * 0.9, -0.16, 0.12]], 0.025, { bendRadius: 0.06 });
    createPart(armName + '_ForeHose', foreHose, jointBlack, { parent: elbowPitch });

    // Arm-mounted Deep-Sea Heavy LED Work Spotlight
    createPart(armName + '_SpotHousing', cylinderGeo(0.09, 0.12, 0.22, 12), hullDark, {
      position: [L2 * 0.65, -0.22, 0],
      rotation: [0, 0, -90],
      parent: elbowPitch
    });
    createPart(armName + '_SpotLens', cylinderGeo(0.085, 0.085, 0.03, 12), floodLight, {
      position: [L2 * 0.65 + 0.12, -0.22, 0],
      rotation: [0, 0, -90],
      parent: elbowPitch
    });

    // 4. Wrist Assembly
    const wristPivot = createPivot(armName + '_Wrist', [L2, 0, 0], elbowPitch);
    wristPivot.rotation.x = d2r(rollDeg);
    wristPivot.rotation.z = d2r(pitch3Deg);

    createPart(armName + '_WristRotator', cylinderGeo(0.15, 0.15, 0.2, 14), safetyYellow, {
      position: [0.1, 0, 0],
      rotation: [0, 0, -90],
      parent: wristPivot
    });
    createPart(armName + '_WristFlange', cylinderGeo(0.17, 0.17, 0.06, 14), jointBlack, {
      position: [0.22, 0, 0],
      rotation: [0, 0, -90],
      parent: wristPivot
    });

    // 5. Tool / Manipulator End-Effector
    const clawBaseX = 0.25;

    if (hasScanner) {
      // Oceanographic Multispectral Scanner Tool Head
      createPart(armName + '_ScannerShaft', cylinderGeo(0.08, 0.08, 0.35, 12), chromeMetal, {
        position: [clawBaseX + 0.18, 0, 0],
        rotation: [0, 0, -90],
        parent: wristPivot
      });
      createPart(armName + '_ScannerHead', cylinderGeo(0.18, 0.14, 0.24, 14), safetyYellow, {
        position: [clawBaseX + 0.42, 0, 0],
        rotation: [0, 0, -90],
        parent: wristPivot
      });
      createPart(armName + '_ScannerLens', sphereGeo(0.12, 14, 10), cyanGlow, {
        position: [clawBaseX + 0.54, 0, 0],
        parent: wristPivot
      });
      createPart(armName + '_ScannerRing', torusGeo(0.19, 0.03, 8, 20), jointBlack, {
        position: [clawBaseX + 0.44, 0, 0],
        rotation: [0, 90, 0],
        parent: wristPivot
      });
    }

    // Heavy 3-Finger Articulated Gripper Claws
    const gripFactor = gripClosed ? 0.35 : 0.9;
    for (let f = 0; f < 3; f++) {
      const phi = (f * 120) * Math.PI / 180;
      const fy = Math.cos(phi) * 0.12;
      const fz = Math.sin(phi) * 0.12;

      // Base knuckle
      createPart(armName + '_FingerKnuckle_' + f, boxGeo(0.1, 0.06, 0.06), safetyYellow, {
        position: [clawBaseX + 0.05, fy, fz],
        parent: wristPivot
      });

      // Proximal heavy phalanx
      beamBetween(armName + '_FingerProx_' + f,
        [clawBaseX + 0.08, fy, fz],
        [clawBaseX + 0.28, fy * 1.15, fz * 1.15],
        0.03, safetyYellow, { parent: wristPivot }
      );

      // Distal hardened chrome claw prong curved inward
      beamBetween(armName + '_FingerDist_' + f,
        [clawBaseX + 0.28, fy * 1.15, fz * 1.15],
        [clawBaseX + 0.48, fy * gripFactor, fz * gripFactor],
        0.022, chromeMetal, { parent: wristPivot }
      );
    }
  }

  // Starboard Heavy Robotic Arm: Posed reaching down toward seabed mineral sample
  buildArticulatedArm('Arm_Stbd', [2.5, 2.5, 1.6], -20, -36, 46, -10, 22, true, false);

  // Port Heavy Robotic Arm: Posed hovering over forward specimen collection basket with active scanner
  buildArticulatedArm('Arm_Port', [2.5, 2.5, -1.6], 30, -18, 34, -16, -28, false, true);

  // ==========================================
  // 5. SEABED BENTHIC BASKET & WORKSTATION
  // ==========================================

  // Forward Specimen Collection Basket [4.1, 0.35, 0]
  createPart('Basket_Base', boxGeo(1.4, 0.08, 0.95), frameworkDark, { position: [4.1, 0.08, 0], parent: root });
  createPart('Basket_FrontRail', boxGeo(1.4, 0.05, 0.05), safetyYellow, { position: [4.1, 0.48, 0.47], parent: root });
  createPart('Basket_RearRail', boxGeo(1.4, 0.05, 0.05), safetyYellow, { position: [4.1, 0.48, -0.47], parent: root });
  createPart('Basket_LeftRail', boxGeo(0.05, 0.05, 0.95), safetyYellow, { position: [4.8, 0.48, 0], parent: root });
  createPart('Basket_RightRail', boxGeo(0.05, 0.05, 0.95), safetyYellow, { position: [3.4, 0.48, 0], parent: root });

  // Basket Corner Posts
  createPart('Basket_Post1', boxGeo(0.06, 0.4, 0.06), safetyYellow, { position: [4.77, 0.28, 0.44], parent: root });
  createPart('Basket_Post2', boxGeo(0.06, 0.4, 0.06), safetyYellow, { position: [4.77, 0.28, -0.44], parent: root });
  createPart('Basket_Post3', boxGeo(0.06, 0.4, 0.06), safetyYellow, { position: [3.43, 0.28, 0.44], parent: root });
  createPart('Basket_Post4', boxGeo(0.06, 0.4, 0.06), safetyYellow, { position: [3.43, 0.28, -0.44], parent: root });

  // Sturdy Deployment Support Struts Connecting Basket to Station Lower Hull
  beamBetween('Basket_StrutL', [2.3, 2.2, 0.6], [3.5, 0.45, 0.4], 0.08, frameworkDark, { parent: root });
  beamBetween('Basket_StrutR', [2.3, 2.2, -0.6], [3.5, 0.45, -0.4], 0.08, frameworkDark, { parent: root });

  // Core Sample Canisters inside Basket
  createPart('Canister_1', cylinderGeo(0.09, 0.09, 0.45, 12), chromeMetal, { position: [3.9, 0.32, 0.2], parent: root });
  createPart('Canister_1_Cap', cylinderGeo(0.095, 0.095, 0.07, 12), cyanGlow, { position: [3.9, 0.56, 0.2], parent: root });

  createPart('Canister_2', cylinderGeo(0.09, 0.09, 0.45, 12), safetyYellow, { position: [4.3, 0.32, 0.18], parent: root });
  createPart('Canister_2_Cap', cylinderGeo(0.095, 0.095, 0.07, 12), jointBlack, { position: [4.3, 0.56, 0.18], parent: root });

  createPart('Canister_3', cylinderGeo(0.09, 0.09, 0.45, 12), chromeMetal, { position: [3.8, 0.32, -0.2], parent: root });
  createPart('Canister_3_Cap', cylinderGeo(0.095, 0.095, 0.07, 12), amberBeacon, { position: [3.8, 0.56, -0.2], parent: root });

  // Seabed Hydrothermal Mineral Chimney Spire near Starboard Arm Claw
  createPart('Hydro_Mound', cylinderGeo(0.35, 0.55, 0.25, 12), frameworkDark, { position: [4.3, 0.125, 1.3], parent: root });
  createPart('Hydro_Spire', cylinderGeo(0.14, 0.28, 0.68, 12), hullDark, { position: [4.3, 0.57, 1.3], parent: root });
  createPart('Hydro_VentGlow', sphereGeo(0.09, 10, 8), amberBeacon, { position: [4.3, 0.92, 1.3], parent: root });

  // Oceanographic Subsea Sensor Tether Cable Connecting Chimney to Station Hull
  const hydroTether = pipeAlongPath([[2.2, 2.2, 1.2], [3.2, 0.3, 1.3], [4.3, 0.15, 1.3]], 0.035, { bendRadius: 0.15 });
  createPart('Hydro_SensorTether', hydroTether, jointBlack, { parent: root });

  // ==========================================
  // 6. EXTERIOR FLOODLIGHTS & UMBILICALS
  // ==========================================

  // Dual Forward Heavy LED Floodlight Pods aimed at seabed sampling
  createPart('Flood_FwdL_Bracket', boxGeo(0.1, 0.1, 0.2), frameworkDark, { position: [2.5, 3.2, 0.85], parent: root });
  createPart('Flood_FwdL_Housing', cylinderGeo(0.16, 0.22, 0.32, 12), hullDark, {
    position: [2.7, 3.1, 0.85],
    rotation: [-22, 15, 0],
    parent: root
  });
  createPart('Flood_FwdL_Lens', cylinderGeo(0.15, 0.15, 0.03, 12), floodLight, {
    position: [2.82, 3.05, 0.88],
    rotation: [-22, 15, 0],
    parent: root
  });

  createPart('Flood_FwdR_Bracket', boxGeo(0.1, 0.1, 0.2), frameworkDark, { position: [2.5, 3.2, -0.85], parent: root });
  createPart('Flood_FwdR_Housing', cylinderGeo(0.16, 0.22, 0.32, 12), hullDark, {
    position: [2.7, 3.1, -0.85],
    rotation: [-22, -15, 0],
    parent: root
  });
  createPart('Flood_FwdR_Lens', cylinderGeo(0.15, 0.15, 0.03, 12), floodLight, {
    position: [2.82, 3.05, -0.88],
    rotation: [-22, -15, 0],
    parent: root
  });

  return root;
}Scroll code horizontally
Brief and retained revisions
Recorded brief
Deep-sea research station with safety orange habitat pod frames, glass habitat pods, and yellow robotic arms.
Saved revision 1
Deep-sea benthic research station featuring pressurized glass habitat pods, dual high-visibility yellow articulated robotic manipulator arms, 4-point seabed landing legs, sample collection basket, and life-support systems.
Download saved revision 1 sourceSHA-256: e97067e161facb990414aa10e0efc58f34c23321cf8b8f2776172963971ce200
Saved revision 2 · Shown here
Deep-sea research station with safety orange habitat pod frames, glass habitat pods, and yellow robotic arms.
Download saved revision 2 sourceSHA-256: df6b76e688d9d5e6a23da05ed1fdac1a3d2975ca7f573ee00b0638e90edb27e8