Trebuchet
Timber frame, counterweight and throwing arm
Earlier examples from earlier Kiln versions.
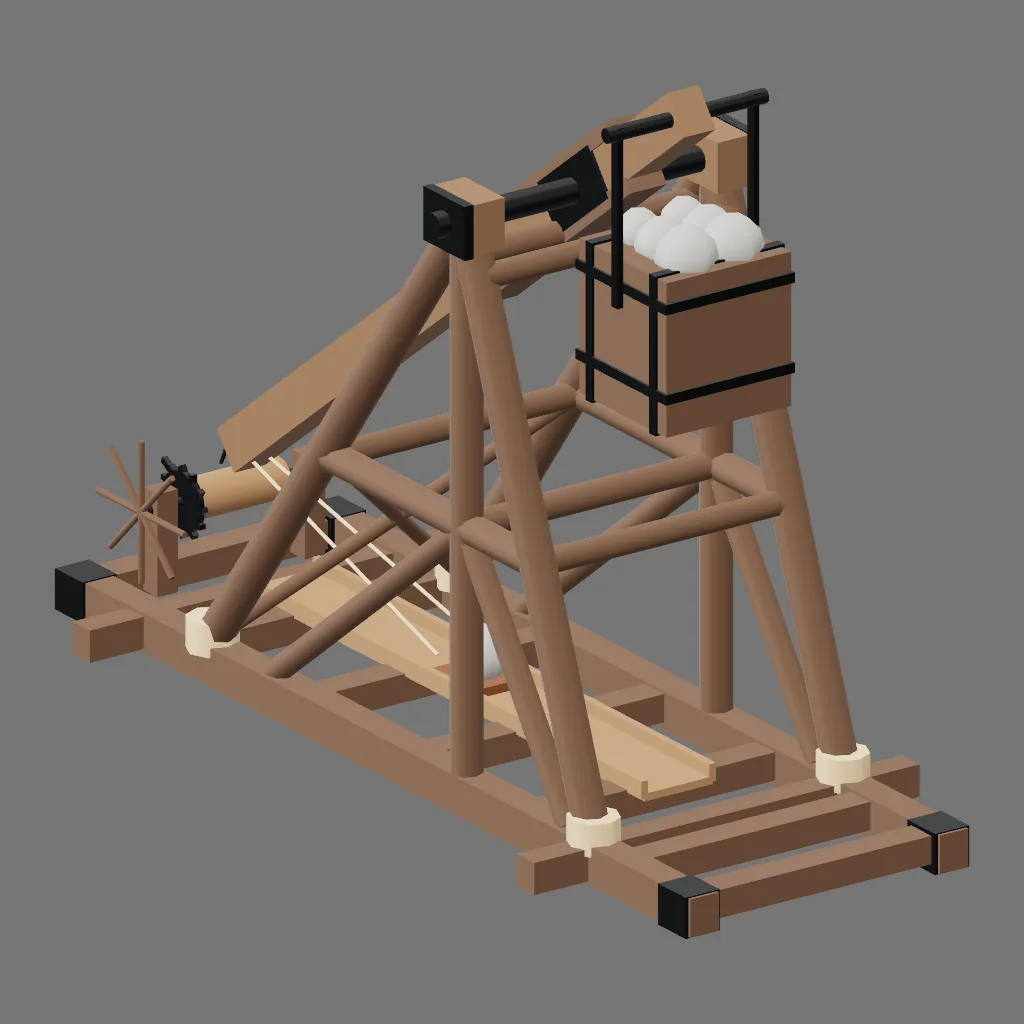
Drag to orbit after opening. The model starts stationary.
For your engine. The download is a standard glTF 2.0 binary (GLB) with PBR metallic-roughness materials. glTF stores materials, not lighting or tone mapping, so your engine decides how they read. This 3D view tone-maps with Review Neutral, the Khronos PBR Neutral construction with a smaller glare offset (0.015 instead of 0.04), at exposure 0.9. Its Tone mapping control also shows ACES and Linear, for comparison.
Build measurements
- Triangles
- 2,652
- Estimated draws
- 93
- Materials
- 7
- Textures
- 0
- Animation clips
- 0
- Bounds X × Y × Z
- 8.05 × 5.73 × 3.4 m
- Build warnings
- 0
Measurements come from this build.
Download this build
Runtime: 75,684 bytes. Original: 75,460 bytes.
These GLBs are build outputs of the MIT-licensed example source; no separate terms are stated for the builds.
Runtime provenance metadataSHA-256 download hashes
- Runtime GLB
- 6f89fa31e2a3574e132a8354c93d544c48f1cf9e408d8693be4f0dbc31e1d3fa
- Original GLB
- ee9fd7aa5ebd43db938c405fb05cd745250c0580f6946d03b13d7993bc06dc7c
- Source
- 94d40bcb59df7e5dd976d663b6adf6a27ebecbb3d948d62dc5c50e40688e1595
The example source is part of the Kiln repository. Repository licence: MIT.
These GLBs are build outputs of the MIT-licensed example source; no separate terms are stated for the builds.
Recorded authorship
Gemini 3.8 Flash through Antigravity CLI (agy)
Source-header credit
- Source access
- Source header declares no repository implementation or finished examples supplied
- Inherited context
- Not independently recorded; source-header declarations only
- Starting example
- None supplied, according to source header
- Human input
- Not recorded
- Authoring review
- Not recorded
Gallery GPU render of this exact source. Source, artifact, image hashes and camera settings are recorded alongside the poster; the artifact hash names the GLB bytes the image was rendered from, which the downloadable rebuild reproduces byte for byte only on the platform that recorded it.
Poster camera and render recordThe source behind this build
// Authored by: gemini-3.8-flash-high, via agy.
//
// Written by the model itself through the Kiln MCP tools, and cut off
// mid-run rather than finished -- by a provider limit, or by the
// dispatch deadline. The program below is what was on disk when the
// session ended; how many times it had looked at its own contact sheet
// by then is not recorded, so this one does not make the claim the
// others do.
//
// Dispatched into a clean directory containing only the brief and the Kiln
// skills, with no access to this repository or to any finished example.

const meta = { name: 'Trebuchet', category: 'prop' };

function build() {
  const root = createRoot('Trebuchet');

  // Materials
  const woodDark = gameMaterial(0x4a3525, { roughness: 0.85, metalness: 0.05 });
  const woodBeam = gameMaterial(0x5c432d, { roughness: 0.8, metalness: 0.05 });
  const woodLight = gameMaterial(0x705338, { roughness: 0.85, metalness: 0.05 });
  const ironMat = gameMaterial(0x242628, { roughness: 0.45, metalness: 0.85 });
  const ropeMat = gameMaterial(0x998365, { roughness: 0.95, metalness: 0.0 });
  const stoneMat = gameMaterial(0x7a7975, { roughness: 0.9, metalness: 0.05 });
  const leatherMat = gameMaterial(0x5a341a, { roughness: 0.85, metalness: 0.1 });

  // Geometry dimensions
  // Base: length 8.0 along X (-4.8 to 3.2), width 2.4 along Z (-1.2 to 1.2), sits on Y=0
  const baseRunnerGeo = boxGeo(8.0, 0.3, 0.25);
  const runnerY = 0.15;
  const zLeft = -1.1;
  const zRight = 1.1;

  // Runners
  createPart('Runner_Left', baseRunnerGeo, woodDark, { position: [-0.8, runnerY, zLeft], parent: root });
  createPart('Runner_Right', baseRunnerGeo, woodDark, { position: [-0.8, runnerY, zRight], parent: root });

  // Ladder cross rungs (7 rungs)
  const rungGeo = boxGeo(0.25, 0.22, 2.2);
  const rungXs = [-4.6, -3.2, -1.8, -0.4, 1.0, 2.2, 3.0];
  for (let i = 0; i < rungXs.length; i++) {
    createPart(`Rung_${i}`, rungGeo, woodDark, { position: [rungXs[i], runnerY + 0.02, 0], parent: root });
  }

  // Launch trough along center of ladder frame
  const troughBaseGeo = boxGeo(5.0, 0.06, 0.6);
  createPart('Trough_Base', troughBaseGeo, woodLight, { position: [-1.2, runnerY + 0.12, 0], parent: root });
  const troughSideGeo = boxGeo(5.0, 0.14, 0.06);
  createPart('Trough_SideL', troughSideGeo, woodLight, { position: [-1.2, runnerY + 0.18, -0.3], parent: root });
  createPart('Trough_SideR', troughSideGeo, woodLight, { position: [-1.2, runnerY + 0.18, 0.3], parent: root });

  // Outriggers / stabilizers on base
  const outriggerGeo = boxGeo(0.22, 0.25, 3.4);
  createPart('Outrigger_Front', outriggerGeo, woodDark, { position: [1.8, runnerY, 0], parent: root });
  createPart('Outrigger_Rear', outriggerGeo, woodDark, { position: [-3.8, runnerY, 0], parent: root });

  // A-Frame Apex position
  const apexX = 0.2;
  const apexY = 4.6;

  // A-Frame uprights on Left and Right
  const legRadius = 0.14;
  [zLeft, zRight].forEach((z, idx) => {
    const side = idx === 0 ? 'L' : 'R';

    // Front leg: from (1.8, 0.3, z) to (apexX, apexY, z)
    beamBetween(`Leg_Front_${side}`, [1.8, 0.3, z], [apexX, apexY, z], legRadius, woodDark, { parent: root });

    // Rear leg: from (-3.0, 0.3, z) to (apexX, apexY, z)
    beamBetween(`Leg_Rear_${side}`, [-3.0, 0.3, z], [apexX, apexY, z], legRadius, woodDark, { parent: root });

    // Vertical kingpost: from (apexX, 0.3, z) to (apexX, apexY, z)
    beamBetween(`Kingpost_${side}`, [apexX, 0.3, z], [apexX, apexY, z], legRadius * 0.9, woodDark, { parent: root });

    // Horizontal tie beam at Y = 2.2
    beamBetween(`Tie_Horiz_${side}`, [-1.5, 2.2, z], [1.1, 2.2, z], legRadius * 0.85, woodDark, { parent: root });

    // Diagonal braces
    beamBetween(`Brace_Front_${side}`, [0.2, 2.2, z], [1.5, 0.3, z], legRadius * 0.7, woodDark, { parent: root });
    beamBetween(`Brace_Rear_${side}`, [0.2, 2.2, z], [-2.2, 0.3, z], legRadius * 0.7, woodDark, { parent: root });

    // Apex bearing block
    const capGeo = boxGeo(0.5, 0.4, 0.32);
    createPart(`BearingBlock_${side}`, capGeo, woodBeam, { position: [apexX, apexY, z], parent: root });
    const strapGeo = boxGeo(0.52, 0.42, 0.08);
    createPart(`BearingStrap_${side}`, strapGeo, ironMat, { position: [apexX, apexY, z + (idx === 0 ? -0.16 : 0.16)], parent: root });
  });

  // Cross-bracing between trusses (Left & Right)
  beamBetween('Cross_Apex_Front', [apexX + 0.2, apexY - 0.4, zLeft], [apexX + 0.2, apexY - 0.4, zRight], 0.1, woodDark, { parent: root });
  beamBetween('Cross_Apex_Rear', [apexX - 0.2, apexY - 0.4, zLeft], [apexX - 0.2, apexY - 0.4, zRight], 0.1, woodDark, { parent: root });
  beamBetween('Cross_Tie_Mid', [apexX, 2.2, zLeft], [apexX, 2.2, zRight], 0.11, woodDark, { parent: root });
  beamBetween('Cross_Tie_Front', [1.1, 2.2, zLeft], [1.1, 2.2, zRight], 0.1, woodDark, { parent: root });
  beamBetween('Cross_Tie_Rear', [-1.5, 2.2, zLeft], [-1.5, 2.2, zRight], 0.1, woodDark, { parent: root });

  // X-bracing between rear legs
  beamBetween('X_Rear_1', [-1.5, 2.2, zLeft], [-3.0, 0.3, zRight], 0.06, woodDark, { parent: root });
  beamBetween('X_Rear_2', [-1.5, 2.2, zRight], [-3.0, 0.3, zLeft], 0.06, woodDark, { parent: root });

  // Main Axle at apex
  const axleGeo = cylinderZGeo(0.1, 0.1, 2.8, 12);
  createPart('Main_Axle', axleGeo, ironMat, { position: [apexX, apexY, 0], parent: root });

  // Throwing Beam
  // Rotated in cocked position: beam tilted down to rear (-X), short end up to front (+X).
  // Tilt angle around Z: e.g. -38 degrees.
  const beamPivot = createPivot('BeamPivot', [apexX, apexY, 0], root);
  beamPivot.rotation.z = -38 * Math.PI / 180;

  // The beam geometry centered at pivot or offset.
  // Total beam length: 7.2m. Short arm = 1.6m (+X), Long arm = 5.6m (-X).
  // Beam center offset: (1.6 - 5.6) / 2 = -2.0m.
  const beamGeo = boxGeo(7.2, 0.35, 0.28);
  createPart('Throwing_Beam', beamGeo, woodBeam, { position: [-2.0, 0, 0], parent: beamPivot });

  // Beam iron reinforcement bands around pivot
  const ironCollarGeo = boxGeo(0.8, 0.42, 0.34);
  createPart('Beam_Collar', ironCollarGeo, ironMat, { position: [0, 0, 0], parent: beamPivot });

  // Beam taper / reinforcement cheeks
  const cheekGeo = boxGeo(2.4, 0.12, 0.32);
  createPart('Beam_CheekTop', cheekGeo, woodDark, { position: [-0.5, 0.22, 0], parent: beamPivot });
  createPart('Beam_CheekBottom', cheekGeo, woodDark, { position: [-0.5, -0.22, 0], parent: beamPivot });

  // Release finger at long beam tip
  // Beam tip is at local X = -5.6
  const fingerGeo = cylinderXGeo(0.025, 0.015, 0.5, 8);
  createPart('Release_Finger', fingerGeo, ironMat, { position: [-5.7, 0.1, 0], rotation: [0, 0, 25], parent: beamPivot });
  const fingerRingGeo = torusGeo(0.06, 0.015, 8, 16);
  createPart('Finger_BaseRing', fingerRingGeo, ironMat, { position: [-5.55, 0.05, 0], rotation: [0, 90, 0], parent: beamPivot });

  // Trunnion axle on short end of beam (local X = 1.5)
  const trunnionAxleGeo = cylinderZGeo(0.06, 0.06, 1.4, 10);
  createPart('Trunnion_Axle', trunnionAxleGeo, ironMat, { position: [1.5, 0, 0], parent: beamPivot });

  // Counterweight:
  // Must hang vertically free! So create counterweight pivot attached to root at trunnion world position.
  // Let's find trunnion world position:
  // Apex = (apexX, apexY, 0). Short arm is at angle -38 deg.
  // dx = 1.5 * cos(-38 deg) = 1.5 * 0.788 = 1.182
  // dy = 1.5 * sin(-38 deg) = 1.5 * (-0.615) = -0.923 (wait, rotation around Z: +38 tilts short arm UP if +X goes to +Y!)
  // In Three.js: rotation around Z: x' = x*cos(theta) - y*sin(theta); y' = x*sin(theta) + y*cos(theta)
  // With theta = +38 deg: x' = 1.5*cos(38) = 1.18, y' = 1.5*sin(38) = 0.92.
  // If we want short arm UP and long arm DOWN: theta should be positive (+35 deg)!
  // Let's adjust beamPivot rotation:
  // theta = 38 deg.
  // Short arm (+X) goes to X = apexX + 1.5*cos(38°) = 0.2 + 1.18 = 1.38, Y = apexY + 1.5*sin(38°) = 4.6 + 0.92 = 5.52.
  // Long arm (-X) goes to X = apexX - 5.6*cos(38°) = 0.2 - 4.41 = -4.21, Y = apexY - 5.6*sin(38°) = 4.6 - 3.45 = 1.15.
  // Perfect!
  beamPivot.rotation.z = 38 * Math.PI / 180;

  const trunnionX = apexX + 1.5 * Math.cos(38 * Math.PI / 180);
  const trunnionY = apexY + 1.5 * Math.sin(38 * Math.PI / 180);

  // Counterweight hangs straight down from (trunnionX, trunnionY, 0)
  const cwPivot = createPivot('CounterweightPivot', [trunnionX, trunnionY, 0], root);

  // Counterweight suspension arms (iron hangers on left and right)
  const hangerArmGeo = boxGeo(0.08, 1.4, 0.05);
  createPart('Hanger_L', hangerArmGeo, ironMat, { position: [0, -0.65, -0.6], parent: cwPivot });
  createPart('Hanger_R', hangerArmGeo, ironMat, { position: [0, -0.65, 0.6], parent: cwPivot });

  // Counterweight box: wooden crate with iron straps
  const boxW = 1.1;
  const boxH = 1.2;
  const boxD = 1.1;
  const cwBoxGeo = boxGeo(boxW, boxH, boxD);
  createPart('CW_Box', cwBoxGeo, woodDark, { position: [0, -1.6, 0], parent: cwPivot });

  // Iron straps around counterweight box
  const strapHGeo = boxGeo(boxW + 0.04, 0.08, boxD + 0.04);
  createPart('CW_Strap_H1', strapHGeo, ironMat, { position: [0, -1.2, 0], parent: cwPivot });
  createPart('CW_Strap_H2', strapHGeo, ironMat, { position: [0, -1.9, 0], parent: cwPivot });
  const strapVGeo = boxGeo(0.08, boxH + 0.04, boxD + 0.04);
  createPart('CW_Strap_V1', strapVGeo, ironMat, { position: [-0.4, -1.6, 0], parent: cwPivot });
  createPart('CW_Strap_V2', strapVGeo, ironMat, { position: [0.4, -1.6, 0], parent: cwPivot });

  // Ballast rocks visible on top of counterweight box
  for (let i = 0; i < 6; i++) {
    const rockGeo = sphereGeo(0.18 + (i % 3) * 0.03, 6, 6);
    const rx = ((i % 3) - 1) * 0.3;
    const rz = (Math.floor(i / 3) - 0.5) * 0.4;
    createPart(`CW_Rock_${i}`, rockGeo, stoneMat, { position: [rx, -0.95, rz], parent: cwPivot });
  }

  // Beam tip world position:
  const tipX = apexX - 5.6 * Math.cos(38 * Math.PI / 180);
  const tipY = apexY - 5.6 * Math.sin(38 * Math.PI / 180);

  // Windlass assembly at rear (-X)
  const windlassX = -4.3;
  const windlassY = 0.55;

  // Upright support posts for windlass
  const winPostGeo = boxGeo(0.18, 0.8, 0.18);
  createPart('WinPost_L', winPostGeo, woodDark, { position: [windlassX, windlassY, -0.65], parent: root });
  createPart('WinPost_R', winPostGeo, woodDark, { position: [windlassX, windlassY, 0.65], parent: root });

  // Windlass drum axle
  const drumAxleGeo = cylinderZGeo(0.04, 0.04, 1.6, 10);
  createPart('Windlass_Axle', drumAxleGeo, ironMat, { position: [windlassX, windlassY + 0.25, 0], parent: root });

  // Wooden winding drum in center
  const drumGeo = cylinderZGeo(0.16, 0.16, 0.8, 12);
  createPart('Windlass_Drum', drumGeo, woodLight, { position: [windlassX, windlassY + 0.25, 0], parent: root });

  // Ratchet wheel and pawl
  const ratchetDiscGeo = cylinderZGeo(0.24, 0.24, 0.05, 16);
  createPart('Ratchet_Disc', ratchetDiscGeo, ironMat, {
    position: [windlassX, windlassY + 0.25, 0.45],
    parent: root
  });
  const toothGeo = boxGeo(0.08, 0.04, 0.05);
  for (let i = 0; i < 12; i++) {
    const angle = (i / 12) * Math.PI * 2;
    createPart(`Ratchet_Tooth_${i}`, toothGeo, ironMat, {
      position: [windlassX + Math.cos(angle) * 0.24, windlassY + 0.25 + Math.sin(angle) * 0.24, 0.45],
      rotation: [0, 0, (angle * 180 / Math.PI) + 30],
      parent: root
    });
  }
  const pawlGeo = boxGeo(0.22, 0.05, 0.04);
  createPart('Ratchet_Pawl', pawlGeo, ironMat, {
    position: [windlassX - 0.15, windlassY + 0.45, 0.45],
    rotation: [0, 0, -30],
    parent: root
  });

  // Windlass spokes / hand wheel on outer right side
  for (let a = 0; a < 4; a++) {
    const spokeGeo = cylinderGeo(0.025, 0.025, 1.1, 8);
    createPart(`WinSpoke_${a}`, spokeGeo, woodDark, {
      position: [windlassX, windlassY + 0.25, 0.82],
      rotation: [0, 0, a * 45],
      parent: root
    });
  }

  // Cocking rope from windlass drum to beam tip hook
  beamBetween('Cocking_Rope', [windlassX, windlassY + 0.35, 0], [tipX, tipY, 0], 0.025, ropeMat, { parent: root });

  // Stone Ball and Leather Pouch in trough
  // Stone ball sits in trough at X = -1.2, Y = 0.45, Z = 0
  const stoneRadius = 0.22;
  const stoneX = -1.2;
  const stoneY = runnerY + 0.12 + 0.03 + stoneRadius;
  const stoneGeo = sphereGeo(stoneRadius, 12, 10);
  createPart('Stone_Shot', stoneGeo, stoneMat, { position: [stoneX, stoneY, 0], parent: root });

  // Leather pouch under and around stone
  const pouchGeo = boxGeo(0.55, 0.08, 0.48);
  createPart('Leather_Pouch', pouchGeo, leatherMat, { position: [stoneX, stoneY - stoneRadius + 0.03, 0], parent: root });

  // Sling ropes running from beam tip to leather pouch
  beamBetween('Sling_Rope_L', [tipX, tipY + 0.05, -0.06], [stoneX - 0.25, stoneY - 0.05, -0.2], 0.015, ropeMat, { parent: root });
  beamBetween('Sling_Rope_R', [tipX, tipY + 0.05, 0.06], [stoneX - 0.25, stoneY - 0.05, 0.2], 0.015, ropeMat, { parent: root });

  // Rope lashings and iron brackets at critical joints
  // Base corners iron straps
  [-4.6, 3.0].forEach(bx => {
    [zLeft, zRight].forEach((bz, bidx) => {
      const cornerStrap = boxGeo(0.35, 0.32, 0.3);
      createPart(`Strap_Base_${bx > 0 ? 'F' : 'R'}_${bidx === 0 ? 'L' : 'R'}`, cornerStrap, ironMat, { position: [bx, runnerY, bz], parent: root });
    });
  });

  // Lashings around A-frame leg bases
  [zLeft, zRight].forEach((z, idx) => {
    const s = idx === 0 ? 'L' : 'R';
    const lashingGeo = cylinderGeo(0.2, 0.2, 0.25, 8);
    createPart(`Lash_Front_${s}`, lashingGeo, ropeMat, { position: [1.8, 0.35, z], parent: root });
    createPart(`Lash_Rear_${s}`, lashingGeo, ropeMat, { position: [-3.0, 0.35, z], parent: root });
  });

  return root;
}Scroll code horizontally
Brief and retained revisions
No brief or earlier revisions are recorded. The source download contains the version built for this page.