Mech
Articulated limbs with fitted armour panels
Earlier examples from earlier Kiln versions.
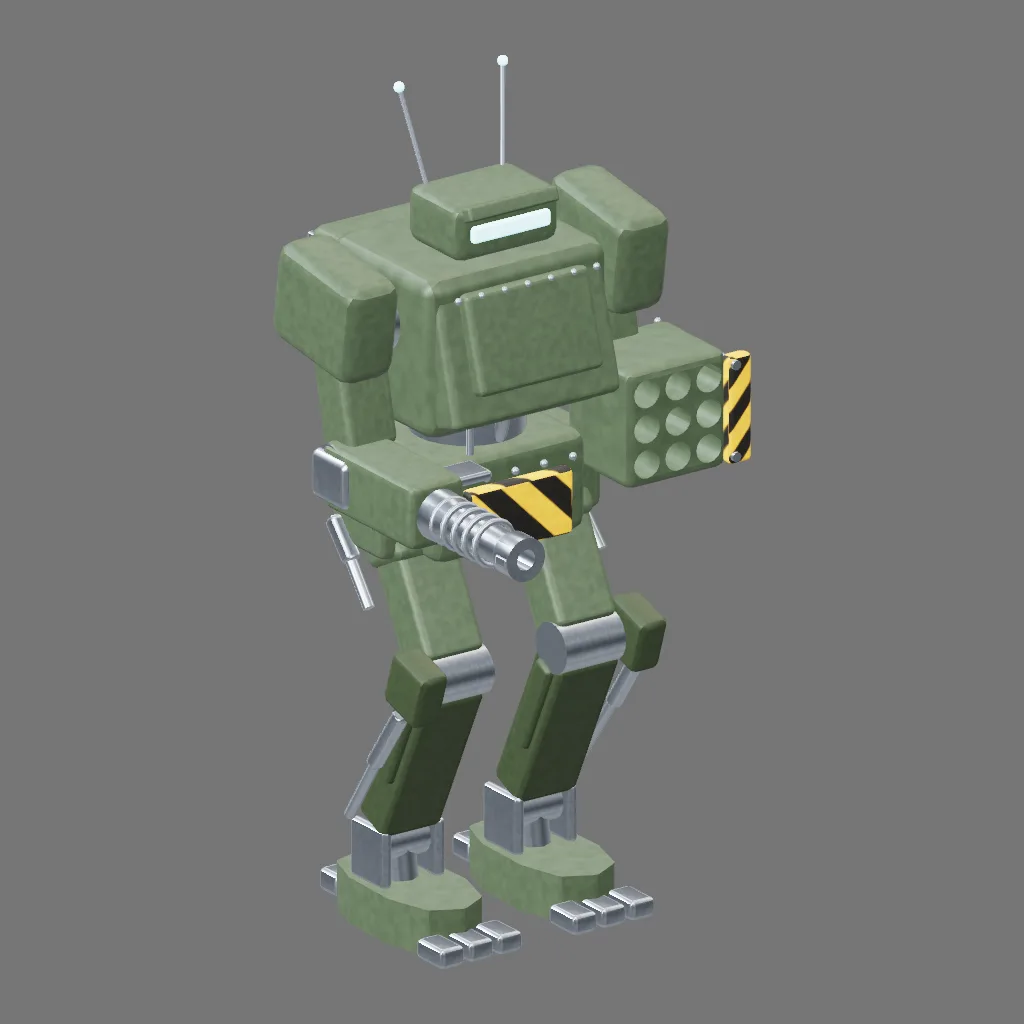
Drag to orbit after opening. The model starts stationary.
For your engine. The download is a standard glTF 2.0 binary (GLB) with PBR metallic-roughness materials. Optional extensions declared by this file: KHR_materials_emissive_strength. Importer support varies; see the Blender and Unity guide. glTF stores materials, not lighting or tone mapping, so your engine decides how they read. This 3D view tone-maps with Review Neutral, the Khronos PBR Neutral construction with a smaller glare offset (0.015 instead of 0.04), at exposure 0.9. Its Tone mapping control also shows ACES and Linear, for comparison.
Build measurements
- Triangles
- 18,298
- Estimated draws
- 135
- Materials
- 7
- Textures
- 8
- Animation clips
- 0
- Bounds X × Y × Z
- 2.88 × 5.05 × 2.56 m
- Build warnings
- 0
Measurements come from this build.
Download this build
Runtime: 1,995,752 bytes. Original: 1,995,536 bytes.
These GLBs are build outputs of the MIT-licensed example source; no separate terms are stated for the builds.
Runtime provenance metadataSHA-256 download hashes
- Runtime GLB
- 844ec7028b11839cdf6cf7f8932efc089e959942f44c604024c10379b0500ed8
- Original GLB
- 1e352e3c29e05749c310899531595102f6bb4ab01a06fe086a5bbfbfd9126c17
- Source
- c0924f2e075f5cb240fefb75c02475d7a36dcdffb1ad152f22d042ce4245cf89
The example source is part of the Kiln repository. Repository licence: MIT.
These GLBs are build outputs of the MIT-licensed example source; no separate terms are stated for the builds.
Recorded authorship
Claude Opus 5 through Claude Code
Source-header credit
- Source access
- Not recorded
- Inherited context
- Not independently recorded; source-header declarations only
- Starting example
- Not recorded
- Human input
- Not recorded
- Authoring review
- Not recorded
Gallery GPU render of this exact source. Source, artifact, image hashes and camera settings are recorded alongside the poster; the artifact hash names the GLB bytes the image was rendered from, which the downloadable rebuild reproduces byte for byte only on the platform that recorded it.
Poster camera and render recordThe source behind this build
// A reverse-jointed industrial walker.
//
// Every other hero in this repository is a thing that exists, and the reference
// does the arguing. A mech has no reference photograph, so the only thing
// holding it together is INTERNAL CONSISTENCY: the joints have to be joints, the
// pistons have to shorten when the leg folds, the armour has to be panels with
// edges and fasteners rather than a shrink-wrap, and every plate has to look
// like it was bolted on by someone who could reach it.
//
// The technique this file exists for is orienting flat armour along a bone.
// beamBetween will run a cylinder between any two points, which is why limbs
// built from it read as pipe-cleaners. A mech needs flat plate, and a box only
// aligns to a bone if you rotate it. Both legs lie in a plane of constant Z, so
// the whole rotation collapses to one angle about Z:
//
//   rotZ = -atan2(dx, dy)
//
// measured from +Y, which is the axis a box's height runs along. That one line
// is what lets armour, hydraulics and hardpoints all be placed by naming two
// joint positions instead of by guessing Euler triples.
//
// Authored by: Claude Opus 5, via Claude Code. Every part below was written by the model itself,
// looking at its own renders through the Kiln tools and revising.
const meta = { name: 'Walker', category: 'vehicle', role: 'hero' };

async function build() {
  const root = createRoot('Walker');
  const uv = (g) => autoUnwrap(g, { resolution: 1024 });
  const D = Math.PI / 180;

  // ---------- Bone maths ----------
  const mid = (a, b) => [(a[0] + b[0]) / 2, (a[1] + b[1]) / 2, (a[2] + b[2]) / 2];
  const dist = (a, b) => Math.hypot(b[0] - a[0], b[1] - a[1], b[2] - a[2]);
  const boneRot = (a, b) => -Math.atan2(b[0] - a[0], b[1] - a[1]) / D;
  // Point a fraction f along a bone, for hanging hardpoints off it.
  const along = (a, b, f) => [0, 1, 2].map((k) => a[k] + (b[k] - a[k]) * f);

  // ---------- Materials ----------
  const armorAlbedo = proceduralTexture({
    schemaVersion: 2, size: 1024, usage: 'albedo', name: 'ArmorPlate',
    layers: [
      { op: 'solid', color: 0x55604f },
      { op: 'noise', colorA: 0x424c3e, colorB: 0x6f7b67, scale: 40, octaves: 4, seed: 5, blend: 'overlay', opacity: 0.50 },
      { op: 'noise', colorA: 0x38402f, colorB: 0x55604f, scale: 14, octaves: 3, seed: 23, blend: 'multiply', opacity: 0.14 },
    ],
  });
  // Painted plate over armour steel. Paint is a DIELECTRIC: at high metalness
  // this whole machine becomes a dark mirror and every panel edge disappears.
  const armor = pbrMaterial({
    albedo: armorAlbedo, normal: normalMapFromHeight(armorAlbedo, { strength: 1.6 }),
    roughness: 0.52, metalness: 0.15,
  });

  const steelAlbedo = proceduralTexture({
    schemaVersion: 2, size: 512, usage: 'albedo', name: 'MachinedSteel',
    layers: [
      { op: 'solid', color: 0x8d939a },
      { op: 'noise', colorA: 0x767c83, colorB: 0xacb2b9, scale: 44, octaves: 3, seed: 11, blend: 'overlay', opacity: 0.50 },
    ],
  });
  // Bare machined steel: rams, joint pins, the gun. This is the material that
  // says which parts move.
  const steel = pbrMaterial({
    albedo: steelAlbedo, normal: normalMapFromHeight(steelAlbedo, { strength: 1.0 }),
    roughness: 0.28, metalness: 0.94,
  });

  // Caution striping, on the pelvis and the pod cover -- the two places a crew
  // chief would actually put it, because they are the two things that swing.
  const hazardAlbedo = proceduralTexture({
    schemaVersion: 2, size: 512, usage: 'albedo', name: 'Hazard',
    layers: [
      { op: 'stripes', colorA: 0xd6a11c, colorB: 0x1f1e1b, count: 7, angleDeg: 45 },
      { op: 'noise', colorA: 0x3a3830, colorB: 0xbcbcb2, scale: 30, octaves: 4, seed: 31, blend: 'overlay', opacity: 0.35 },
    ],
  });
  const hazard = pbrMaterial({
    albedo: hazardAlbedo, normal: normalMapFromHeight(hazardAlbedo, { strength: 1.2 }),
    roughness: 0.58, metalness: 0.10,
  });

  // A second, darker armour value. One paint colour over a five-metre machine
  // flattens it: every plate reads at the same tone and the silhouette does all
  // the work alone. Real vehicles are repainted in panels and the lower legs are
  // the parts that get scuffed and resprayed, so darkening those separates the
  // legs from the torso without inventing a fantasy colour.
  const armorDarkAlbedo = proceduralTexture({
    schemaVersion: 2, size: 1024, usage: 'albedo', name: 'ArmorPlateDark',
    layers: [
      { op: 'solid', color: 0x454f3a },
      { op: 'noise', colorA: 0x363f2c, colorB: 0x5a664f, scale: 40, octaves: 4, seed: 5, blend: 'overlay', opacity: 0.50 },
      { op: 'noise', colorA: 0x2c3323, colorB: 0x454f3a, scale: 14, octaves: 3, seed: 23, blend: 'multiply', opacity: 0.16 },
    ],
  });
  const armorDark = pbrMaterial({
    albedo: armorDarkAlbedo, normal: normalMapFromHeight(armorDarkAlbedo, { strength: 1.6 }),
    roughness: 0.54, metalness: 0.15,
  });

  const hose = gameMaterial(0x17171a, { roughness: 0.90, metalness: 0.0 });
  const canopy = glassMaterial(0x2b4f56, { opacity: 0.52, roughness: 0.05, metalness: 0 });
  const glow = gameMaterial(0x9ff0ff, { emissive: 0x3ad6ee, emissiveIntensity: 3.2, roughness: 0.40 });

  // ---------- Helpers ----------
  const plate = async (name, w, h, d, r, position, opts = {}) =>
    createPart(name, await uv(await roundedBoxGeo(w, h, d, r)), opts.mat ?? armor, {
      position, rotation: opts.rotation, parent: opts.parent ?? root,
    });

  // Armour laid ALONG a bone: sized to the bone length, centred on it, and
  // turned by the single Z angle derived above.
  const boneArmor = async (name, a, b, w, d, r, grow = 0.0, mat = armor) =>
    plate(name, w, dist(a, b) + grow, d, r, mid(a, b), { rotation: [0, 0, boneRot(a, b)], mat });

  // A ring of fasteners around a panel edge. Bolts are the cheapest thing in the
  // asset and they are most of what separates armour from a beveled cube.
  const boltRow = (name, from, to, count, r = 0.024) => {
    for (let i = 0; i < count; i++) {
      const f = count === 1 ? 0.5 : i / (count - 1);
      createPart(`${name}_${i}`, sphereGeo(r, 8, 6), steel, {
        position: [0, 1, 2].map((k) => from[k] + (to[k] - from[k]) * f), parent: root,
      });
    }
  };

  // ---------- Legs ----------
  // Digitigrade: the knee breaks FORWARD and high, the shin sweeps back, and the
  // ankle sits over the middle of a long foot. A mech with human knees reads as
  // a person in a costume.
  for (const sz of [-1, 1]) {
    const side = sz > 0 ? 'R' : 'L';
    const HIP = [0.00, 2.58, sz * 0.44];
    const KNEE = [0.48, 1.66, sz * 0.48];
    const ANKLE = [-0.04, 0.56, sz * 0.46];

    // Thigh: a steel ram inside a two-piece armour shell.
    beamBetween(`ThighRam_${side}`, HIP, KNEE, 0.085, steel, { parent: root });
    await boneArmor(`ThighPlate_${side}`, HIP, KNEE, 0.30, 0.40, 0.045, -0.18);
    await boneArmor(`ThighShoulder_${side}`, HIP, along(HIP, KNEE, 0.34), 0.38, 0.48, 0.06, 0.0);

    // Knee: a real pin joint, and an armour cap over it so the pin is not the
    // outermost thing on the leg.
    createPart(`KneePin_${side}`, cylinderZGeo(0.155, 0.155, 0.46, 20), steel, { position: KNEE, parent: root });
    await plate(`KneeCap_${side}`, 0.34, 0.36, 0.20, 0.05, [KNEE[0] + 0.10, KNEE[1] + 0.02, KNEE[2] + sz * 0.28], {
      rotation: [0, 0, -18], mat: armorDark,
    });

    // Shin. Darker paint below the knee, so the leg separates from the torso.
    beamBetween(`ShinRam_${side}`, KNEE, ANKLE, 0.075, steel, { parent: root });
    await boneArmor(`ShinPlate_${side}`, KNEE, ANKLE, 0.28, 0.42, 0.045, -0.16, armorDark);
    await boneArmor(`ShinGuard_${side}`, along(KNEE, ANKLE, 0.10), along(KNEE, ANKLE, 0.62), 0.16, 0.50, 0.04, 0.0, armorDark);

    // Hydraulics. Each is a sleeve on the fixed half and a bright rod on the
    // moving half, offset OUTBOARD of the armour so it is visible -- a piston
    // buried inside a limb is triangles nobody will ever see.
    const hipAnchor = [HIP[0] - 0.20, HIP[1] - 0.10, HIP[2] + sz * 0.34];
    const thighMid = along(HIP, KNEE, 0.58);
    const thighRamEnd = [thighMid[0] - 0.10, thighMid[1], thighMid[2] + sz * 0.34];
    beamBetween(`ThighPistonRod_${side}`, hipAnchor, thighRamEnd, 0.038, steel, { parent: root });
    await boneArmor(`ThighPistonBody_${side}`, hipAnchor, mid(hipAnchor, thighRamEnd), 0.10, 0.10, 0.03, 0.0, steel);

    const kneeAnchor = [KNEE[0] + 0.06, KNEE[1] - 0.14, KNEE[2] + sz * 0.36];
    const ankleAnchor = [ANKLE[0] + 0.02, ANKLE[1] + 0.16, ANKLE[2] + sz * 0.34];
    beamBetween(`ShinPistonRod_${side}`, kneeAnchor, ankleAnchor, 0.034, steel, { parent: root });
    await boneArmor(`ShinPistonBody_${side}`, kneeAnchor, mid(kneeAnchor, ankleAnchor), 0.09, 0.09, 0.028, 0.0, steel);

    // Hydraulic lines, sagging the way a hose does rather than running straight.
    const hosePath = bezierCurve([
      [HIP[0] - 0.28, HIP[1] - 0.16, HIP[2] + sz * 0.10],
      [KNEE[0] - 0.34, KNEE[1] + 0.42, KNEE[2] + sz * 0.06],
      [KNEE[0] - 0.10, KNEE[1] - 0.10, KNEE[2] + sz * 0.02],
      [ANKLE[0] - 0.10, ANKLE[1] + 0.20, ANKLE[2] + sz * 0.04],
    ], 26);
    createPart(`HydraulicLine_${side}`, curveToMesh(hosePath, 0.030, 26, 8), hose, { parent: root });

    // Ankle and foot. The foot is an extruded wedge, not a box: a walker that
    // carries eight tonnes needs a long toe and a heel spur, and the plan shape
    // is the only thing selling the weight.
    createPart(`AnklePin_${side}`, cylinderZGeo(0.125, 0.125, 0.40, 18), steel, {
      position: [ANKLE[0], ANKLE[1] - 0.06, ANKLE[2]], parent: root,
    });
    const footOutline = [
      [0.62, 0.00], [0.52, 0.19], [0.24, 0.27], [-0.16, 0.26],
      [-0.42, 0.17], [-0.46, 0.00], [-0.42, -0.17], [-0.16, -0.26],
      [0.24, -0.27], [0.52, -0.19],
    ];
    createPart(`Foot_${side}`, await uv(await extrudeProfile(footOutline, {
      depth: 0.28, axis: 'y', bevel: 0.035,
    })), armor, { position: [ANKLE[0] + 0.06, 0.14, ANKLE[2]], parent: root });
    // The ankle pin has to actually REACH the foot. Left as a pin floating over a
    // deck, the leg reads as two disconnected props -- the single most damaging
    // error in the first render. A real walker carries the load through a clevis:
    // two cheek plates straddling the pin, bolted down onto the foot deck.
    for (const cz of [-1, 1]) {
      await plate(`AnkleClevis_${side}${cz > 0 ? 'A' : 'B'}`, 0.34, 0.36, 0.07, 0.030,
        [ANKLE[0] + 0.01, 0.45, ANKLE[2] + cz * 0.185], { mat: steel });
    }
    // Load-bearing column down the middle, so the joint is not just two fins.
    beamBetween(`AnkleColumn_${side}`, [ANKLE[0], ANKLE[1] - 0.06, ANKLE[2]],
      [ANKLE[0] + 0.04, 0.26, ANKLE[2]], 0.105, steel, { parent: root });
    // Toe claws.
    for (const tz of [-1, 0, 1]) {
      createPart(`Toe_${side}${tz + 1}`, await uv(await roundedBoxGeo(0.26, 0.12, 0.17, 0.030)), steel, {
        position: [ANKLE[0] + 0.72, 0.075, ANKLE[2] + tz * 0.20], parent: root,
      });
    }
    createPart(`HeelSpur_${side}`, await uv(await roundedBoxGeo(0.20, 0.14, 0.26, 0.035)), steel, {
      position: [ANKLE[0] - 0.50, 0.085, ANKLE[2]], parent: root,
    });

    // Hip actuator housing.
    createPart(`HipPin_${side}`, cylinderZGeo(0.185, 0.185, 0.30, 20), steel, {
      position: [HIP[0], HIP[1], HIP[2] + sz * 0.06], parent: root,
    });
    await plate(`HipHousing_${side}`, 0.52, 0.50, 0.26, 0.06, [HIP[0], HIP[1], HIP[2] + sz * 0.20]);
  }

  // ---------- Pelvis and waist ----------
  await plate('Pelvis', 0.92, 0.62, 1.06, 0.09, [0, 2.62, 0]);
  // The caution panel goes on the swinging cover, not on a random flat.
  await plate('PelvisCover', 0.10, 0.40, 0.72, 0.03, [0.50, 2.56, 0], { mat: hazard });
  boltRow('PelvisBolt', [0.48, 2.80, -0.40], [0.48, 2.80, 0.40], 5);
  createPart('WaistRing', cylinderGeo(0.34, 0.34, 0.26, 24), steel, { position: [0, 3.03, 0], parent: root });
  createPart('WaistCollar', torusGeo(0.36, 0.045, 8, 28), steel, { position: [0, 3.14, 0], parent: root });

  // ---------- Torso ----------
  await plate('Torso', 1.02, 0.98, 1.26, 0.10, [0.02, 3.60, 0]);
  // Sloped glacis over the chest, because a flat vertical front is the one thing
  // no armoured machine has ever had.
  await plate('Glacis', 0.24, 0.86, 1.16, 0.05, [0.50, 3.62, 0], { rotation: [0, 0, 16] });
  boltRow('GlacisBoltT', [0.60, 3.98, -0.48], [0.60, 3.98, 0.48], 7, 0.022);
  boltRow('GlacisBoltB', [0.56, 3.24, -0.48], [0.56, 3.24, 0.48], 7, 0.022);

  // Reactor and heat sink on the back, with real fins.
  await plate('ReactorHousing', 0.44, 0.80, 0.98, 0.07, [-0.66, 3.58, 0]);
  for (let i = 0; i < 9; i++) {
    createPart(`HeatFin_${i}`, await uv(await roundedBoxGeo(0.16, 0.62, 0.05, 0.012)), steel, {
      position: [-0.90, 3.58, -0.40 + i * 0.10], parent: root,
    });
  }
  createPart('ReactorGlow', await uv(await roundedBoxGeo(0.06, 0.44, 0.72, 0.02)), glow, {
    position: [-0.86, 3.58, 0], parent: root,
  });

  // ---------- Cockpit ----------
  // The canopy is a real inset: frame first, glass behind it. Glass flush with
  // the hull reads as a painted rectangle.
  await plate('CanopyFrame', 0.14, 0.60, 0.86, 0.04, [0.62, 3.70, 0], { rotation: [0, 0, 16] });
  createPart('Canopy', await uv(await roundedBoxGeo(0.09, 0.48, 0.74, 0.03)), canopy, {
    position: [0.64, 3.70, 0], rotation: [0, 0, 16], parent: root,
  });
  createPart('CockpitGlow', await uv(await roundedBoxGeo(0.03, 0.30, 0.56, 0.01)), glow, {
    position: [0.55, 3.68, 0], rotation: [0, 0, 16], parent: root,
  });
  // Grab handle and the step a pilot uses to get in. Somebody has to board this.
  beamBetween('BoardingHandle', [0.66, 3.24, 0.44], [0.66, 3.06, 0.44], 0.022, steel, { parent: root });
  createPart('BoardingStep', await uv(await roundedBoxGeo(0.22, 0.06, 0.30, 0.02)), steel, {
    position: [0.56, 2.90, 0.44], parent: root,
  });

  // ---------- Sensor head ----------
  await plate('SensorHead', 0.52, 0.34, 0.72, 0.07, [0.16, 4.28, 0]);
  createPart('SensorNeck', cylinderGeo(0.14, 0.16, 0.20, 16), steel, { position: [0.16, 4.10, 0], parent: root });
  createPart('EyeSlit', await uv(await roundedBoxGeo(0.05, 0.10, 0.54, 0.02)), glow, {
    position: [0.43, 4.28, 0], parent: root,
  });
  await plate('EyeBrow', 0.16, 0.09, 0.62, 0.02, [0.40, 4.40, 0], { rotation: [0, 0, 22] });
  for (const sz of [-1, 1]) {
    beamBetween(`Antenna_${sz > 0 ? 'R' : 'L'}`,
      [-0.02, 4.42, sz * 0.26], [-0.16, 5.02, sz * 0.36], 0.014, steel, { parent: root });
    createPart(`AntennaTip_${sz > 0 ? 'R' : 'L'}`, sphereGeo(0.032, 10, 8), glow, {
      position: [-0.16, 5.02, sz * 0.36], parent: root,
    });
  }

  // ---------- Shoulders ----------
  for (const sz of [-1, 1]) {
    const side = sz > 0 ? 'R' : 'L';
    createPart(`ShoulderPin_${side}`, cylinderZGeo(0.20, 0.20, 0.34, 20), steel, {
      position: [0.04, 3.74, sz * 0.74], parent: root,
    });
    await plate(`Pauldron_${side}`, 0.78, 0.62, 0.38, 0.10, [0.04, 3.86, sz * 0.94], { rotation: [0, 0, -8] });
    boltRow(`PauldronBolt${side}`, [-0.26, 4.10, sz * 0.94], [0.30, 4.10, sz * 0.94], 4, 0.022);
  }

  // ---------- Right arm: autocannon ----------
  {
    const SH = [0.04, 3.66, 0.80];
    const ELBOW = [0.20, 2.98, 0.92];
    beamBetween('UpperArmRamR', SH, ELBOW, 0.085, steel, { parent: root });
    await boneArmor('UpperArmPlateR', SH, ELBOW, 0.30, 0.34, 0.05, -0.14);
    createPart('ElbowPinR', cylinderZGeo(0.135, 0.135, 0.34, 18), steel, { position: ELBOW, parent: root });

    await plate('GunBody', 0.92, 0.40, 0.38, 0.06, [0.58, 2.92, 0.92]);
    await plate('GunReceiver', 0.36, 0.30, 0.44, 0.05, [0.24, 2.92, 0.92], { mat: steel });
    // A bored barrel, not a rod with a dark cap on the end. The bore is a real
    // boolean, so it survives being looked at down the muzzle.
    // First pass made this too thin and it read as a grey pipe. A cannon that
    // fires something worth mounting on an eight-tonne chassis has a barrel you
    // can see from the side, so every radius here went up by about half.
    const barrelSolid = new THREE.Mesh(await revolveProfile([
      [0.000, 1.02], [0.155, 1.02], [0.146, 1.16], [0.112, 1.30],
      [0.106, 1.72], [0.132, 1.76], [0.132, 1.90], [0.000, 1.90],
    ], { segments: 32, axis: 'x', smooth: true }), steel);
    const bore = new THREE.Mesh(cylinderXGeo(0.062, 0.062, 1.10, 20), steel);
    bore.position.set(1.46, 0, 0);
    const barrel = await boolDiff('Barrel', barrelSolid, bore, { smooth: true });
    barrel.name = 'Barrel';
    barrel.geometry = await uv(barrel.geometry);
    barrel.position.set(0, 2.92, 0.92);
    root.add(barrel);
    // Vented cooling shroud. The ring of slots down the jacket is the detail
    // that actually says "autocannon" rather than "tube", and stacked rings
    // cost far less than boring twenty real holes through the barrel.
    for (let s = 0; s < 5; s++) {
      const sx = 1.16 + s * 0.105;
      createPart(`ShroudRing_${s}`, torusGeo(0.132, 0.020, 8, 20), steel, {
        position: [sx, 2.92, 0.92], rotation: [0, 90, 0], parent: root,
      });
    }
    // Muzzle brake ports.
    for (const bz of [-1, 1]) {
      createPart(`MuzzlePort_${bz > 0 ? 'R' : 'L'}`, await uv(await roundedBoxGeo(0.11, 0.06, 0.05, 0.014)), steel, {
        position: [1.84, 2.92, 0.92 + bz * 0.115], parent: root,
      });
    }
    // Ammo feed from the torso, as a chain of links rather than one grey tube.
    const feed = bezierCurve([
      [-0.10, 3.30, 0.62], [0.10, 3.16, 0.86], [0.16, 3.02, 0.94], [0.22, 2.98, 0.92],
    ], 16);
    createPart('AmmoFeed', curveToMesh(feed, 0.052, 16, 8), hose, { parent: root });
    createPart('FeedCollar', torusGeo(0.062, 0.016, 8, 16), steel, {
      position: [0.12, 3.14, 0.88], rotation: [40, 0, 30], parent: root,
    });
  }

  // ---------- Left arm: missile pod ----------
  {
    const SH = [0.04, 3.66, -0.80];
    const ELBOW = [0.18, 3.02, -0.92];
    beamBetween('UpperArmRamL', SH, ELBOW, 0.085, steel, { parent: root });
    await boneArmor('UpperArmPlateL', SH, ELBOW, 0.30, 0.34, 0.05, -0.14);
    createPart('ElbowPinL', cylinderZGeo(0.135, 0.135, 0.34, 18), steel, { position: ELBOW, parent: root });

    // Nine real tubes, bored through the block. Nine dark discs painted on a
    // face is the version of this that falls apart the moment the camera moves.
    const podSolid = new THREE.Mesh(await roundedBoxGeo(0.62, 0.72, 0.70, 0.06), armor);
    const tubes = [];
    for (let r = -1; r <= 1; r++) {
      for (let c = -1; c <= 1; c++) {
        const t = new THREE.Mesh(cylinderXGeo(0.088, 0.088, 0.80, 16), armor);
        t.position.set(0.10, r * 0.215, c * 0.215);
        tubes.push(t);
      }
    }
    const pod = await boolDiff('MissilePod', podSolid, ...tubes, { smooth: true });
    pod.name = 'MissilePod';
    pod.geometry = await uv(pod.geometry);
    pod.position.set(0.44, 2.98, -0.94);
    root.add(pod);

    await plate('PodCover', 0.09, 0.66, 0.16, 0.03, [0.76, 2.98, -1.34], { mat: hazard });
    for (const hy of [-1, 1]) {
      createPart(`PodHinge_${hy > 0 ? 'U' : 'D'}`, cylinderXGeo(0.030, 0.030, 0.16, 10), steel, {
        position: [0.74, 2.98 + hy * 0.28, -1.30], parent: root,
      });
    }
    boltRow('PodBolt', [0.12, 3.32, -1.24], [0.12, 2.64, -1.24], 4, 0.022);
  }

  return root;
}Scroll code horizontally
Brief and retained revisions
No brief or earlier revisions are recorded. The source download contains the version built for this page.