Abyssal surveyor
Custom curved hull, guarded thrusters and articulated sampling arm
Earlier examples from earlier Kiln versions.
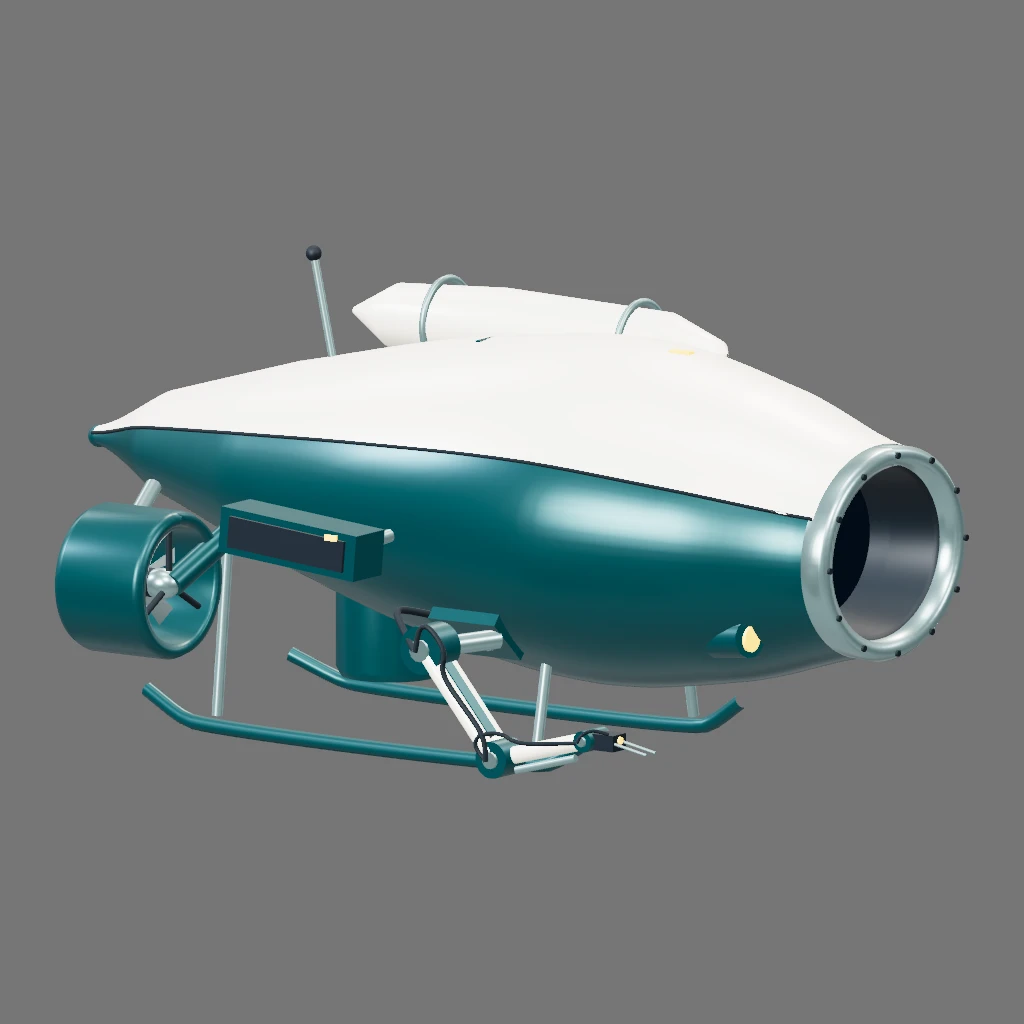
Drag to orbit after opening. The model starts stationary.
For your engine. The download is a standard glTF 2.0 binary (GLB) with PBR metallic-roughness materials. glTF stores materials, not lighting or tone mapping, so your engine decides how they read. This 3D view tone-maps with Review Neutral, the Khronos PBR Neutral construction with a smaller glare offset (0.015 instead of 0.04), at exposure 0.9. Its Tone mapping control also shows ACES and Linear, for comparison.
Build measurements
- Triangles
- 34,456
- Estimated draws
- 115
- Materials
- 6
- Textures
- 0
- Animation clips
- 1
- Bounds X × Y × Z
- 3.17 × 1.54 × 1.86 m
- Build warnings
- 0
Measurements come from this build.
Download this build
Runtime: 635,756 bytes. Original: 635,524 bytes.
These GLBs are build outputs of the MIT-licensed example source; no separate terms are stated for the builds.
Runtime provenance metadataSHA-256 download hashes
- Runtime GLB
- 6471defad0e67a392c3ea7b69425e189a71c71ad9a4c7e7e1deb8c53f20342ab
- Original GLB
- c635988c3a37a2d3925c3e8b3c95c1370c390b1444409827fe8386672b4b7fe2
- Source
- 3fad8e8c92fbcbc535007bc08db6ff2564d08ac0cbfb840b355e58ae85c0b633
The example source is part of the Kiln repository. Repository licence: MIT.
These GLBs are build outputs of the MIT-licensed example source; no separate terms are stated for the builds.
Recorded authorship
GPT-6 Astra through Codex ·
Recorded Codex / gpt-6-astra creative authoring run; configured model, no provider-internal attestation
- Source access
- Local art-directed brief, installed skills and tool definitions; no engine implementation or finished examples observed.
- Inherited context
- Fresh creative authoring conversation.
- Starting example
- None supplied.
- Human input
- Maintainer supplied the brief and independently verified exports and images. Model repaired arm attachment and rear skid supports by reference; no hand-edited source geometry.
- Authoring review
- GPU whole, detail and animated-arm views delivered and reviewed. Coherent curved hull and attached mechanism; hidden clearance and engineering function not verified. The run reached its 15-minute limit while copying an image after valid source/GLB exports; final notes were unfinished.
Gallery GPU render of this exact source. Source, artifact, image hashes and camera settings are recorded alongside the poster; the artifact hash names the GLB bytes the image was rendered from, which the downloadable rebuild reproduces byte for byte only on the platform that recorded it.
Poster camera and render recordThe source behind this build
const meta={name:"LANTERN / S-4",category:"vehicle",role:"vehicle"};
const HULL_Y=1.28;
const ARM_ROOT=[0.28,0.91,0.79];
function skin(stations,a0=0,a1=Math.PI*2,steps=72){
 const p=[],ix=[],uv=[];
 for(let j=0;j<stations.length;j++){const s=stations[j];for(let k=0;k<=steps;k++){const t=a0+(a1-a0)*k/steps;p.push(s[0],s[3]+s[1]*Math.cos(t),s[2]*Math.sin(t));uv.push(j/(stations.length-1),k/steps);}}
 for(let j=0;j<stations.length-1;j++)for(let k=0;k<steps;k++){let a=j*(steps+1)+k,b=a+steps+1;ix.push(a,a+1,b,b,a+1,b+1);}
 return meshGeo({positions:p,indices:ix,uvs:uv});
}
function fairStations(){
 const knots=[[-1.57,.025,.035,1.30],[-1.28,.16,.22,1.31],[-.8,.31,.43,1.30],[-.15,.47,.61,1.28],[.50,.55,.67,1.26],[1.03,.47,.56,1.24],[1.48,.34,.40,1.23]];
 const out=[];
 for(let i=0;i<knots.length-1;i++)for(let j=0;j<10;j++){let t=j/10;let row=[];for(let c=0;c<4;c++){let a=knots[Math.max(0,i-1)][c],b=knots[i][c],d=knots[i+1][c],e=knots[Math.min(knots.length-1,i+2)][c];row.push(c===0?b+(d-b)*t:.5*((2*b)+(-a+d)*t+(2*a-5*b+4*d-e)*t*t+(-a+3*b-3*d+e)*t*t*t));}out.push(row);}
 out.push(knots[knots.length-1]);return out;
}
function build(){
 const root=createRoot("LANTERN_S4");
 const teal=gameMaterial(0x12484c,{metalness:.48,roughness:.32,flatShading:false});
 const ivory=gameMaterial(0xe5dfcb,{metalness:.15,roughness:.34,flatShading:false});
 const black=gameMaterial(0x101c23,{metalness:.2,roughness:.55,flatShading:false});
 const steel=gameMaterial(0x819a9a,{metalness:.78,roughness:.25,flatShading:false});
 const glass=gameMaterial(0x071e2c,{metalness:.55,roughness:.13,flatShading:false});
 const amber=gameMaterial(0xffbb51,{emissive:0xff961d,emissiveIntensity:.65,roughness:.24,flatShading:false});
 const add=(n,g,m,pos=[0,0,0],parent=root,rot=[0,0,0],scale=[1,1,1])=>createPart(n,g,m,{position:pos,parent,rotation:rot,scale});
 const beam=(n,a,b,r,m,parent=root)=>beamBetween(n,a,b,r,m,{parent,segments:12});
 const pipe=(n,pts,r,m,parent=root)=>add(n,pipeAlongPath(pts,r,{bendRadius:.025,tubularSegments:40,radialSegments:8}),m,[0,0,0],parent);
 const stations=fairStations();
 add("Pressure_body_custom_teardrop",skin(stations),teal);
 add("Ivory_upper_fairing",skin(stations.map(s=>[s[0],s[1]+.009,s[2]+.009,s[3]]),-1.10,1.10,36),ivory);
 for(const sign of [-1,1])pipe("Fairing_separation_"+sign,stations.map(s=>[s[0],s[3]+(s[1]+.011)*Math.cos(1.1),sign*(s[2]+.011)*Math.sin(1.1)]),.006,black);
 add("Tail_closure",sphereGeo(.036,20,12),teal,[-1.57,1.30,0],[root][0]);
 const port=createPivot("Observation_port",[0,0,0],root);
 add("Prow_retaining_lip",skin([[1.46,.345,.405,1.23],[1.53,.347,.407,1.23],[1.555,.321,.38,1.23],[1.54,.286,.341,1.23],[1.48,.283,.338,1.23]]),steel,[0,0,0],port);
 add("Recess_elastomer_gasket",skin([[1.485,.284,.339,1.23],[1.47,.272,.327,1.23],[1.31,.256,.307,1.23]]),black,[0,0,0],port);
 add("Port_shadow_well",skin([[1.32,.259,.311,1.23],[1.21,.247,.298,1.23]]),black,[0,0,0],port);
 add("Inset_pressure_glazing",cylinderXGeo(.25,.25,.025,64),glass,[1.225,1.23,0],port,[0,0,0],[1,1,1.20]);
 for(let i=0;i<12;i++){let t=i*Math.PI/6;add("Port_captive_fastener_"+i,cylinderXGeo(.011,.011,.009,8),black,[1.558,1.23+.322*Math.cos(t),.38*Math.sin(t)],port);}
 // One long port-side buoyancy cartridge, carried off the pressure skin.
 const pod=createPivot("Port_buoyancy_cartridge",[-.28,1.66,-.70],root);
 add("Float_streamlined_shell",skin([[-.78,.012,.012,0],[-.61,.105,.125,0],[-.20,.13,.145,0],[.44,.115,.13,0],[.64,.045,.060,0],[.68,.005,.006,0]],0,Math.PI*2,40),ivory,[0,0,0],pod);
 for(const x of [-.70,.06]){beam("Float_saddle_"+x,[x,1.51,-.45],[x,1.62,-.72],.033,teal);add("Float_band_"+x,torusGeo(.133,.013,8,36),steel,[x,1.66,-.70],root,[0,90,0],[1,1.04,1]);}
 // Starboard side-scan instrument: a compact faceted blade with dark acoustic face.
 const survey=createPivot("Starboard_survey_instrument",[-.19,1.22,.84],root);
 add("Side_scan_body",boxGeo(.53,.15,.16),teal,[0,0,0],survey,[0,0,-5]);
 add("Acoustic_ceramic_face",boxGeo(.45,.102,.014),black,[0,0,.084],survey,[0,0,-5]);
 for(const x of [-.37,.01])beam("Instrument_standoff_"+x,[x,1.23,.55],[x,1.22,.79],.022,steel);
 add("Survey_status_light",boxGeo(.045,.019,.009),amber,[.18,.04,.094],survey);
 function thruster(label,x,y,z,r){
  const mount=createPivot(label,[x,y,z],root);
  add(label+"_thick_duct",skin([[-.17,r,r,0],[-.14,r+.015,r+.015,0],[.14,r+.015,r+.015,0],[.17,r,r,0],[.16,r-.036,r-.036,0],[-.16,r-.036,r-.036,0],[-.17,r,r,0]],0,Math.PI*2,56),teal,[0,0,0],mount);
  for(const xx of [-.155,.155])add(label+"_rim_"+xx,torusGeo(r-.006,.009,8,56),steel,[xx,0,0],mount,[0,90,0]);
  add(label+"_motor",cylinderXGeo(.047,.047,.16,24),black,[0,0,0],mount);
  add(label+"_spinner",sphereGeo(.051,24,16),steel,[.09,0,0],mount,[0,0,0],[1.3,1,1]);
  for(let k=0;k<5;k++){let t=k*Math.PI*2/5;const verts=[[-.025,.04,0],[.02,r-.047,-.02],[.045,r-.065,.045],[.01,.04,.027]];const pp=[];for(const v of verts)pp.push(v[0],v[1]*Math.cos(t)-v[2]*Math.sin(t),v[1]*Math.sin(t)+v[2]*Math.cos(t));add(label+"_propeller_"+k,meshGeo({positions:pp,indices:[0,1,2,0,2,3,2,1,0,3,2,0]}),steel,[0,0,0],mount);}
  for(let k=0;k<3;k++){let t=k*Math.PI*2/3;beam(label+"_guard_"+k,[.12,.045*Math.cos(t),.045*Math.sin(t)],[.12,(r-.027)*Math.cos(t),(r-.027)*Math.sin(t)],.011,black,mount);}
  return mount;
 }
 for(const side of [-1,1]){
  thruster("Aft_propulsor_"+side,-.94,.99,side*.68,.225);
  beam("Thruster_forward_mount_"+side,[-.77,1.13,side*.40],[-.81,.99,side*.68],.041,teal);
  beam("Thruster_aft_mount_"+side,[-1.19,1.21,side*.24],[-1.08,.99,side*.68],.028,steel);
 }
 const lift=thruster("Ventral_heave_thruster",-.43,.81,0,.16);lift.rotation.z=Math.PI/2;
 // Mounting plate, paired load paths and hardware at the shoulder.
 add("Arm_hull_mounting_plate",boxGeo(.26,.045,.20),teal,[.28,.92,.53],root,[-42,0,0]);
 beam("Shoulder_mount_forward",[.39,.92,.57],ARM_ROOT,.033,steel);
 beam("Shoulder_mount_aft",[.17,.92,.57],ARM_ROOT,.033,steel);
 for(const xx of [.18,.38])add("Mount_captive_bolt_"+xx,cylinderXGeo(.016,.016,.025,8),steel,[xx,.90,.60],root,[0,90,0]);
 const shoulder=createPivot("Arm_shoulder",ARM_ROOT,root);shoulder.rotation.z=-50*Math.PI/180;
 function joint(n,parent,pos,r){add(n,cylinderXGeo(r,r,.115,28),teal,pos,parent,[0,90,0]);add(n+"_axle",cylinderXGeo(r*.46,r*.46,.135,12),steel,pos,parent,[0,90,0]);}
 joint("Shoulder_rotary_housing",shoulder,[0,0,0],.079);
 for(const zz of [-.039,.039])beam("Upper_link_rail_"+zz,[.025,0,zz],[.405,0,zz],.027,ivory,shoulder);
 add("Upper_link_spine",boxGeo(.29,.052,.047),teal,[.21,0,0],shoulder);
 const elbow=createPivot("Arm_elbow",[.43,0,0],shoulder);elbow.rotation.z=65*Math.PI/180;
 joint("Elbow_bearing",elbow,[0,0,0],.06);
 beam("Forearm_tube",[.015,0,0],[.34,0,0],.028,ivory,elbow);
 beam("Forearm_actuator",[.05,-.049,0],[.29,-.049,0],.013,steel,elbow);
 const wrist=createPivot("Arm_wrist",[.37,0,0],elbow);wrist.rotation.z=-15*Math.PI/180;
 joint("Wrist_micro_gimbal",wrist,[0,0,0],.035);
 add("Measurement_head",boxGeo(.085,.053,.072),black,[.064,0,0],wrist);
 for(const zz of [-.026,.026])beam("Fine_conductivity_probe_"+zz,[.1,0,zz],[.23,-.025,zz],.005,steel,wrist);
 add("Tool_optical_tip",cylinderXGeo(.012,.012,.007,20),amber,[.11,.008,0],wrist);
 // Harness segments end concentrically on joint axes; service loops rotate with each link.
 pipe("Shoulder_rotating_service_loop",[[0,0,.087],[-.06,.09,.087],[.075,.10,.087],[.10,.045,.087],[.37,.045,.087],[.43,0,.087]],.009,black,shoulder);
 pipe("Elbow_rotating_service_loop",[[0,0,.087],[-.035,.08,.087],[.08,.085,.087],[.13,.04,.087],[.37,0,.087]],.007,black,elbow);
 pipe("Tool_harness",[[0,0,.087],[.02,.045,.072],[.09,.03,.035]],.006,black,wrist);
 pipe("Hull_to_shoulder_feed",[[.15,.96,.53],[.10,1.01,.73],[ARM_ROOT[0],ARM_ROOT[1],ARM_ROOT[2]+.087]],.012,black);
 // Discrete working lights, skid and mast.
 for(const sign of [-1,1]){
  beam("Lamp_recess_"+sign,[1.09,.96,sign*.35],[1.25,.98,sign*.39],.062,teal);
  add("Warm_work_lamp_"+sign,cylinderXGeo(.042,.042,.012,24),amber,[1.258,.981,sign*.392]);
  pipe("Landing_runner_"+sign,[[-1.10,.58,sign*.40],[-.91,.50,sign*.44],[.50,.50,sign*.44],[.65,.60,sign*.42]],.025,teal);
  for(const xx of [-.8,.45])beam("Runner_strut_"+sign+"_"+xx,[xx,.53,sign*.44],[xx,xx<0?1.17:.88,sign*.37],.018,steel);
 }
 beam("Telemetry_mast",[-.65,1.62,0],[-.73,1.98,0],.013,steel);
 add("Mast_cap",sphereGeo(.026,16,12),black,[-.73,1.98,0]);
 // Purposeful small registration marks atop the broad fairing.
 for(let i=0;i<4;i++)add("S4_registration_bar_"+i,boxGeo(.022,.008,.09),teal,[-.03+i*.045,1.773,.035]);
 add("Safety_index",boxGeo(.08,.009,.032),amber,[.71,1.804,0]);
 return root;
}
function animate(){
 const keys=(a,b,c)=>[{time:0,rotation:[0,0,a]},{time:1.6,rotation:[0,0,b]},{time:3.2,rotation:[0,0,c]},{time:4.8,rotation:[0,0,a]}];
 return [createClip("Survey_reach",4.8,[rotationTrack("Joint_Arm_shoulder",keys(-50,-67,-42)),rotationTrack("Joint_Arm_elbow",keys(65,43,52)),rotationTrack("Joint_Arm_wrist",keys(-15,24,-10))])];
}Scroll code horizontally
Brief and retained revisions
Brief summary
Design a roughly 3.2 m deep-ocean survey vehicle with a curved teardrop hull, deep teal structure, warm ivory fairing and sparse amber accents. Integrate a recessed forward port, asymmetric sensor and buoyancy modules, guarded thrusters and an articulated sampling arm. Review its silhouette, underside and arm attachment, then repair a visible weakness by source reference.
Initial design
First retained design with the curved hull, survey equipment and articulated arm.
Download initial design sourceSHA-256: d295e88b9f64632665f2a4251fee08b5313cd88887e104be0f556f6954ee1e6a
Arm attachment revision
Moved the shoulder mount, adjusted its plate and supports, added mounting bolts and rerouted the service cable after close-up review.
Download arm attachment revision sourceSHA-256: 1b055f12e8a375e18104eb3268a03cb7550f64de4754ee4bc2fb737f18f407f1
Current gallery revision · Shown here
Adjusted the runner support endpoints to meet the hull. This is the source used for the current downloadable asset; mechanical clearance is not certified.
Download current gallery revision sourceSHA-256: 3fad8e8c92fbcbc535007bc08db6ff2564d08ac0cbfb840b355e58ae85c0b633